 BlinkThorLabs
An Apology to the Small Components on the RRC Lite Board
Five parts I walked right past on my way to the big square chip in the middle. They deserved better.
Bill brings together vehicle-level ADAS design, embedded perception, functional safety and technical leadership. His work connects the decisions made during architecture and component selection with the evidence needed during integration, validation and release. As Director of ADAS & Functional Safety, he helps partners turn an ambitious feature scope into a coherent engineering program: clear interfaces, explicit safety assumptions, a practical validation strategy and a team able to execute it.
ADAS & Safety Technical Manager, Automotive OEM programs
His experience covers camera, short-, medium- and long-range radar, and ultrasonic sensing across traffic-jam assistance, sign recognition, adaptive cruise control, emergency braking, lane support and blind-spot warning. The work includes system design support, sensor alignment, object tracking, SOP test planning, FOTA validation and traceability reviews. This provides a system-level view of how perception, ECU software, vehicle networks and test evidence must work together.
Functional Safety Manager, Safety-critical automotive software
Bill has led safety-critical software work involving ISO 26262, AUTOSAR Classic and the development of safety cases. His responsibilities have included FMEA, dependent-failure analysis, fault-tree analysis, technical reviews and customer guidance through safety activities. He connects safety requirements to implementation and verification so that the safety argument can be examined alongside the software and system behavior it describes.
Technical leadership, Radar validation, ADAS components and edge AI
Earlier work spans Bosch radar validation, vehicle-level ADAS and electrical/electronic component programs, and embedded vision development in Finland. Responsibilities range from CAN-based ECU integration and requirements-based testing to sensor packaging, DVPR/DFMEA, camera and radar calibration, object detection and tracking. This breadth supports discussions that cross software, sensing hardware, vehicle integration and the operational environment.
Architecture reviews, Technical mentoring, ADAS and safety training
Bill combines delivery leadership with structured technical training. His approach develops engineers who can reason about the full feature, investigate integration failures and explain the relationship between a requirement, an implementation decision and its verification. Partners can work with him on program scoping, design reviews, technical risk, team development and the practical coordination of safety and ADAS workstreams.
His academic background includes a Bachelor’s degree in Computer Engineering and a Master’s degree in Software Engineering with an AI specialization. Professional credentials and training include Functional Safety Engineer training in ISO 26262:2018 through TÜV SÜD (2024), Automotive Cybersecurity Engineer training in ISO/SAE 21434 through Omnex (2024), Advanced ADAS for Self-Driving Cars through the University of Toronto on Coursera (2025), and Test Driven Development for Embedded C (2018).
Bill is a strong fit for partners developing an ADAS feature or an integrated vehicle platform that needs both engineering depth and a clear delivery structure. Engagements can combine feature definition, architecture, perception and sensor integration, safety analysis, verification planning and technical mentoring. He works with the team to make complex decisions understandable, establish the evidence that matters and move systematically from a concept to an inspectable solution.
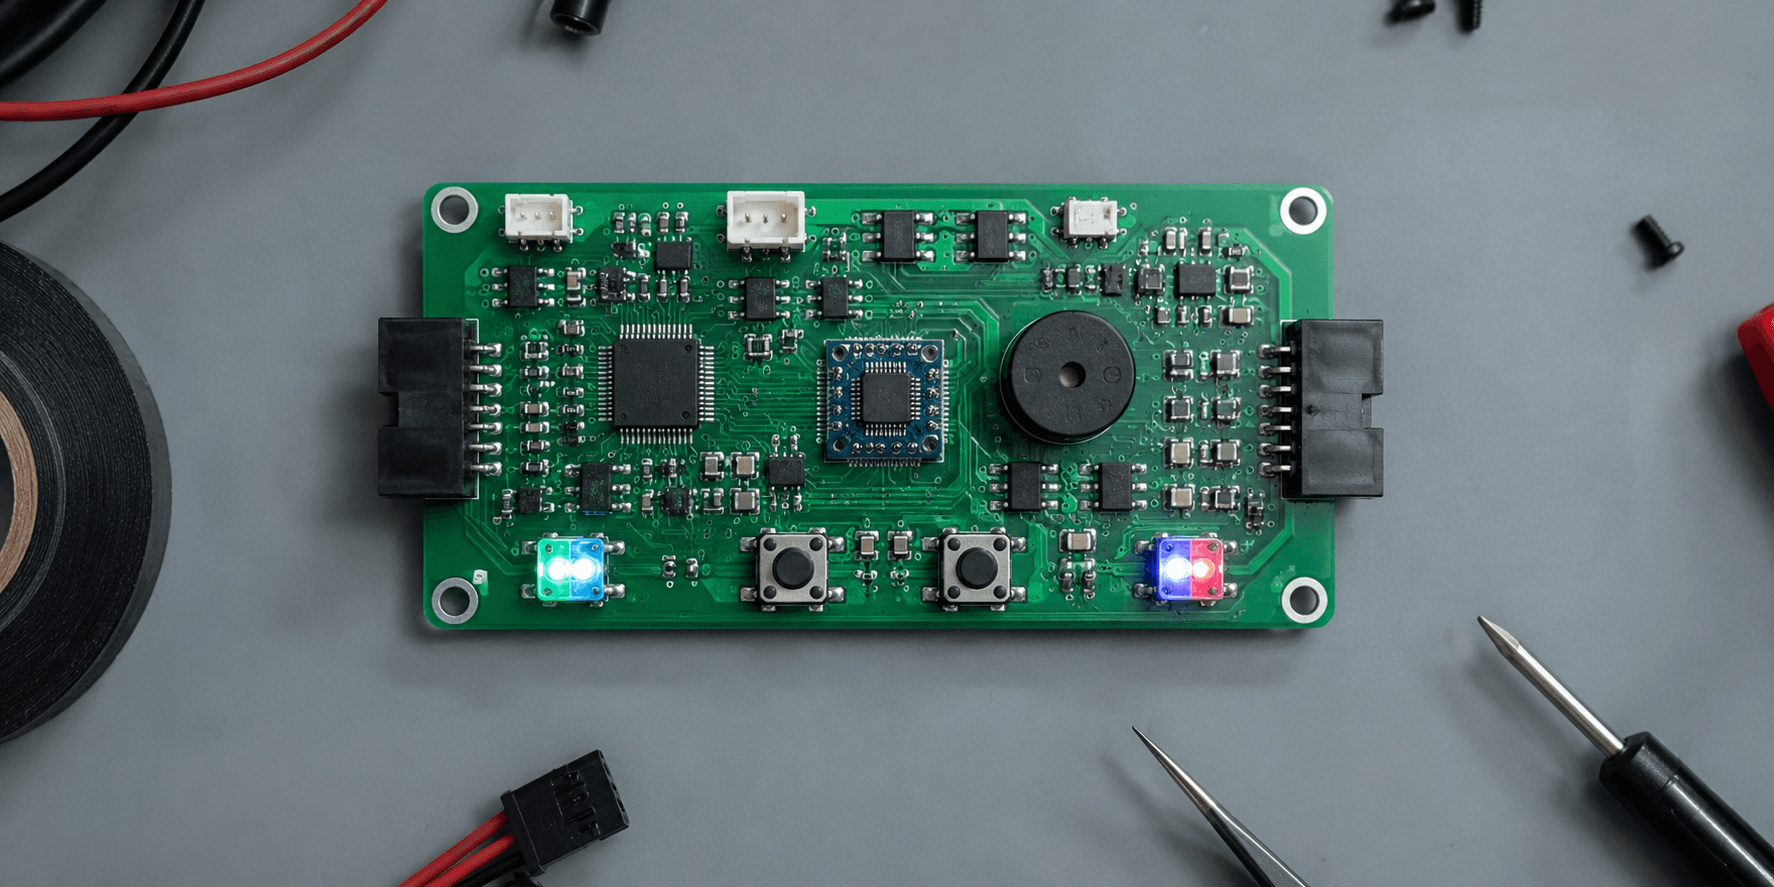
Five parts I walked right past on my way to the big square chip in the middle. They deserved better.
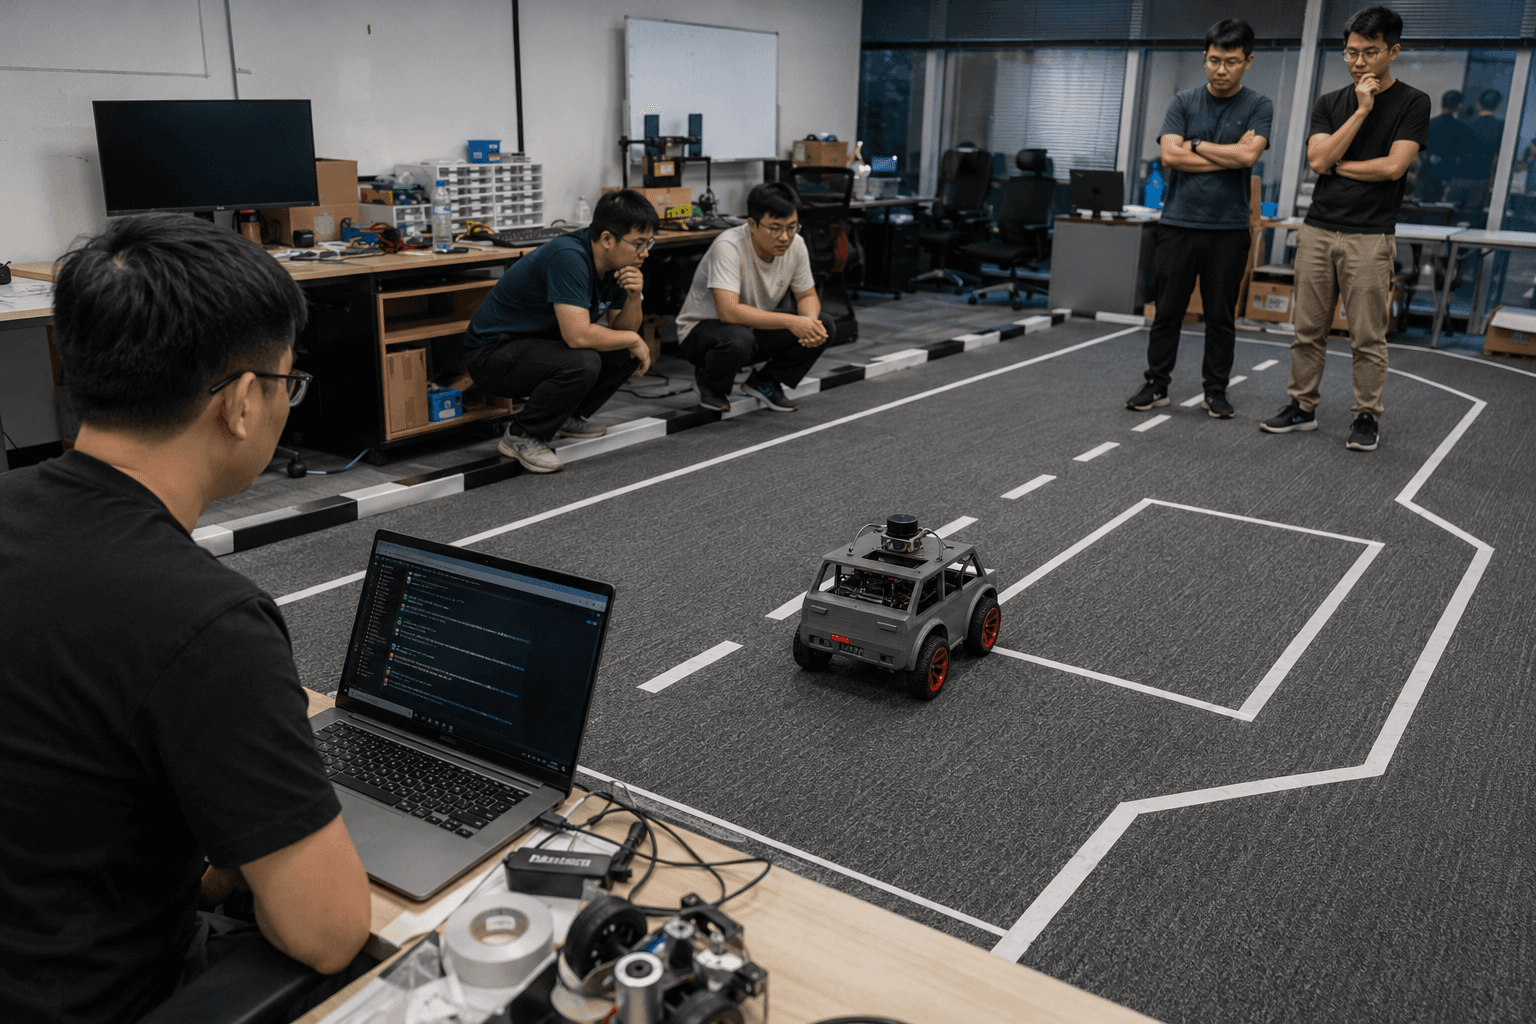
Live, present tense, as it happens. One park_action() function, one Ackermann steering formula, and a room full of colleagues watching.
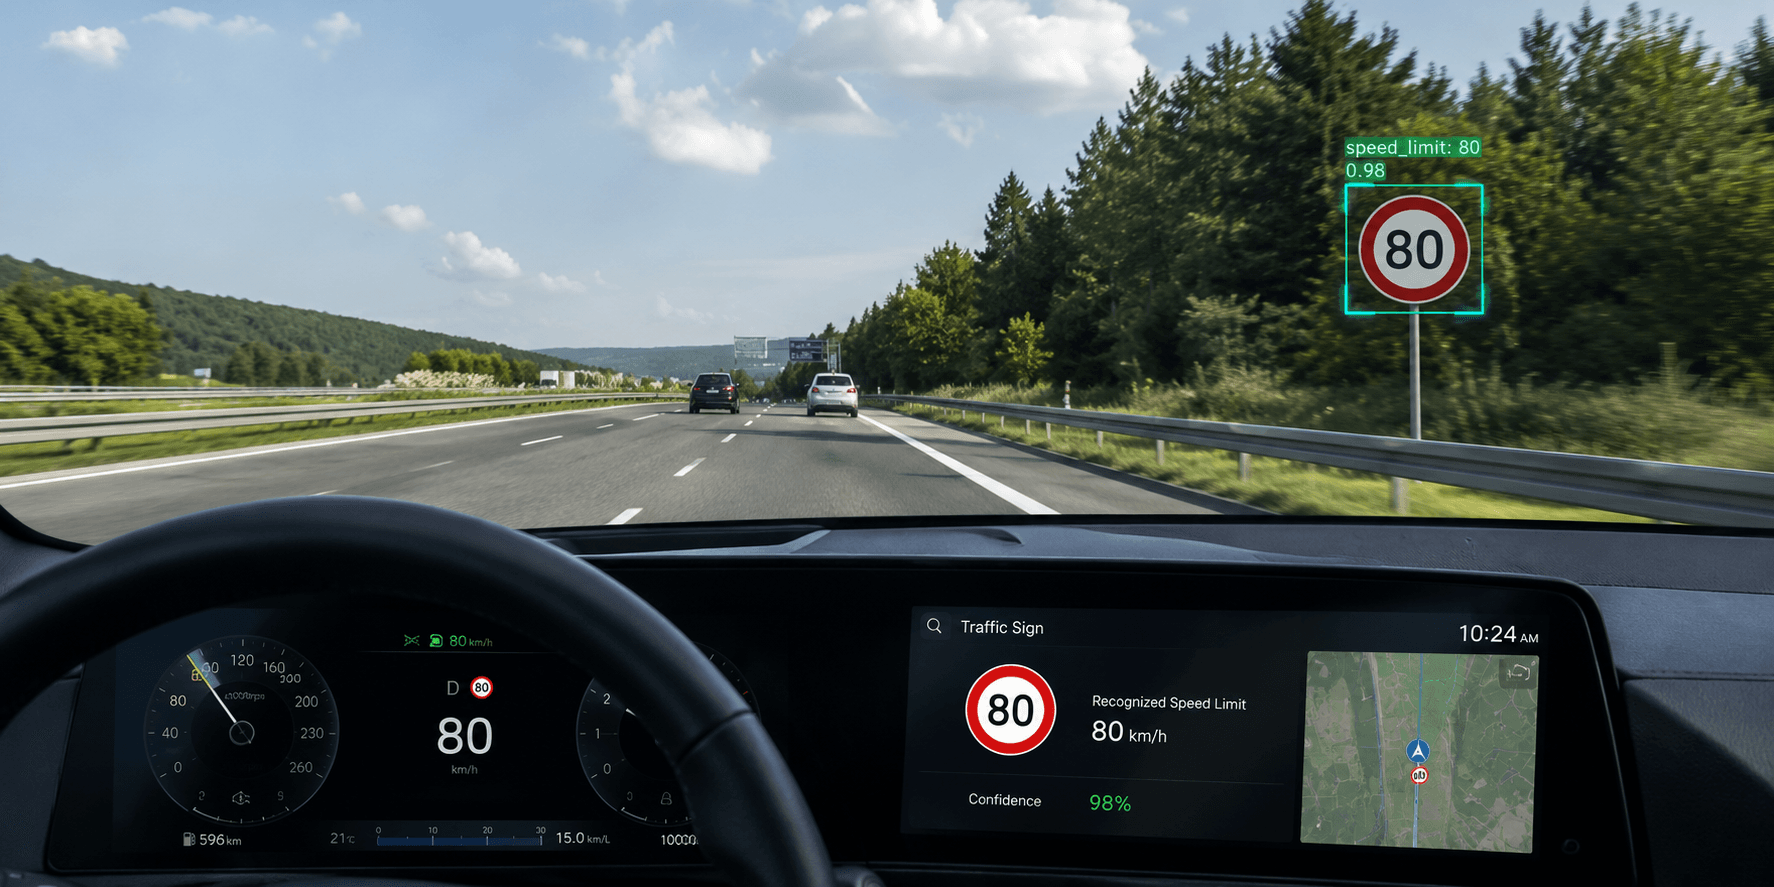
Detection finds it, classification names it, temporal fusion decides whether to trust it. Here's the full path.
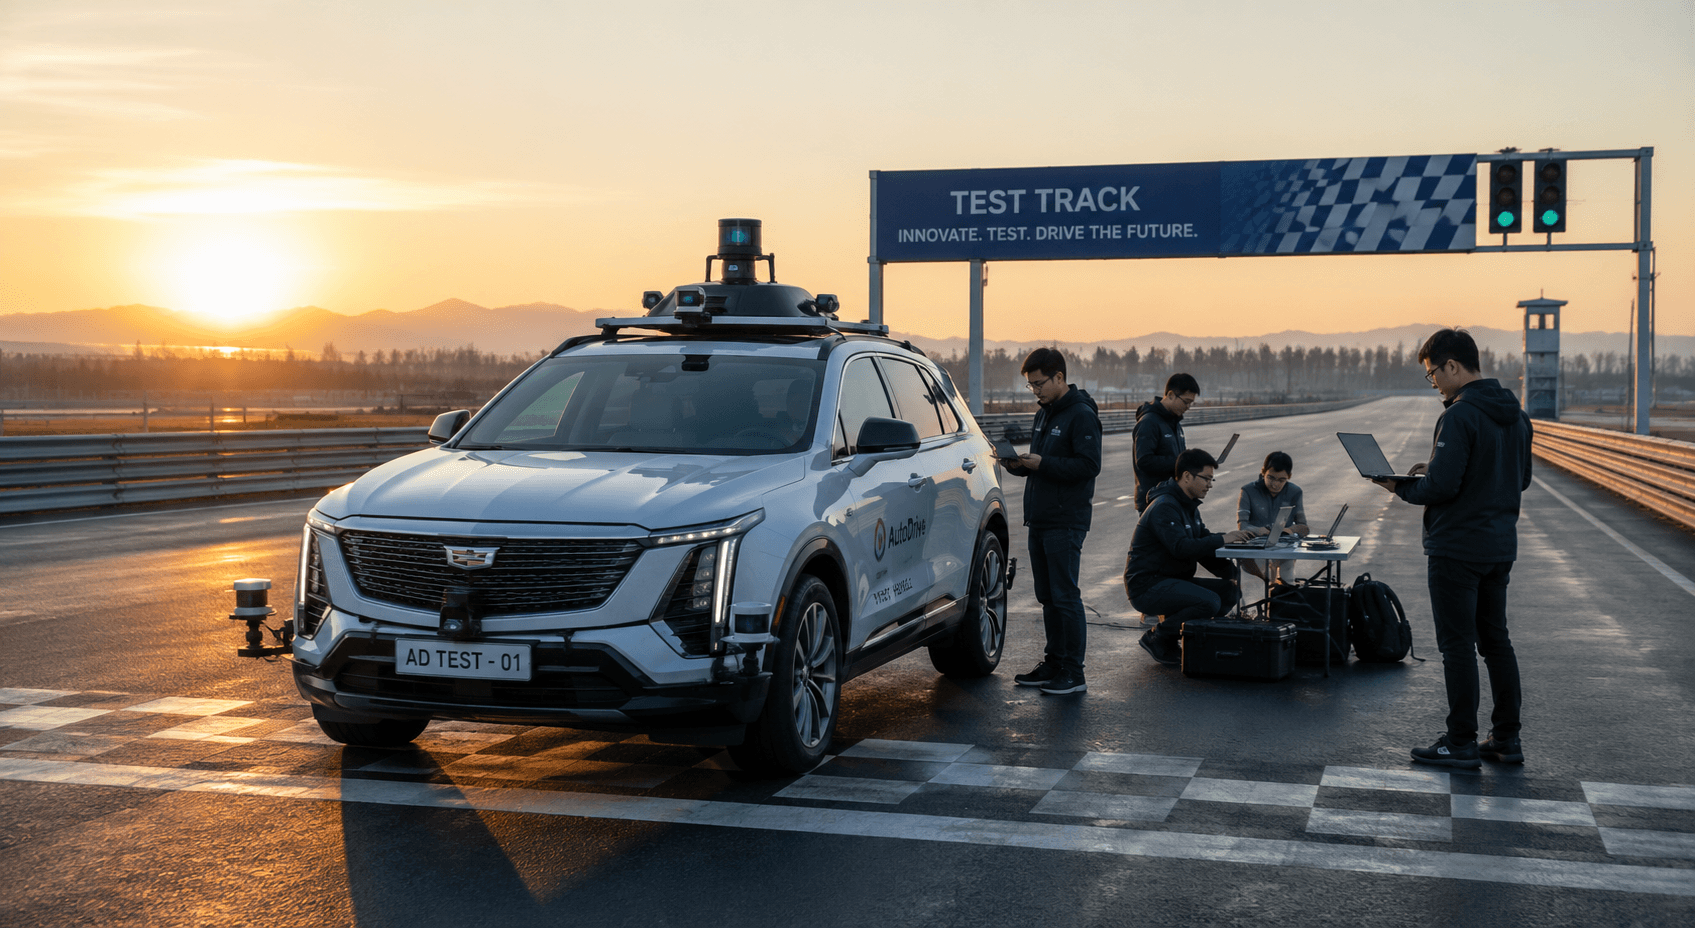
Live, present tense, as it happens. Months of bench and simulation come down to the next ninety seconds.
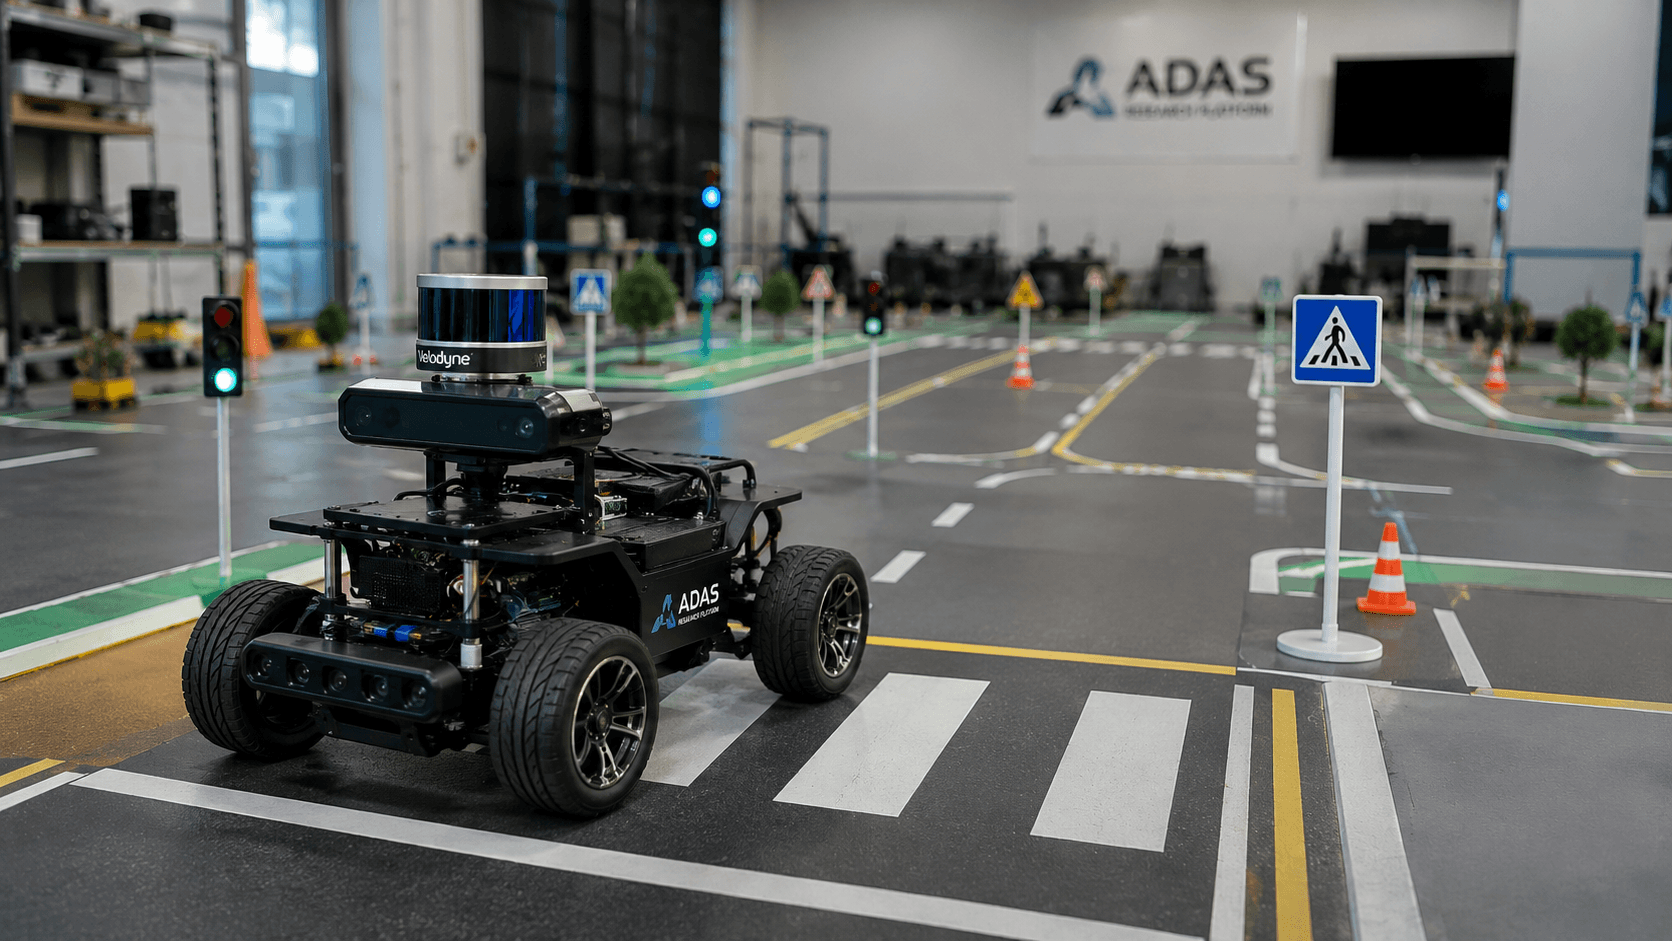
Perception, planning, vehicle control, safety logic, and HMI — at 1/10 scale, on a desk, without touching a real car.
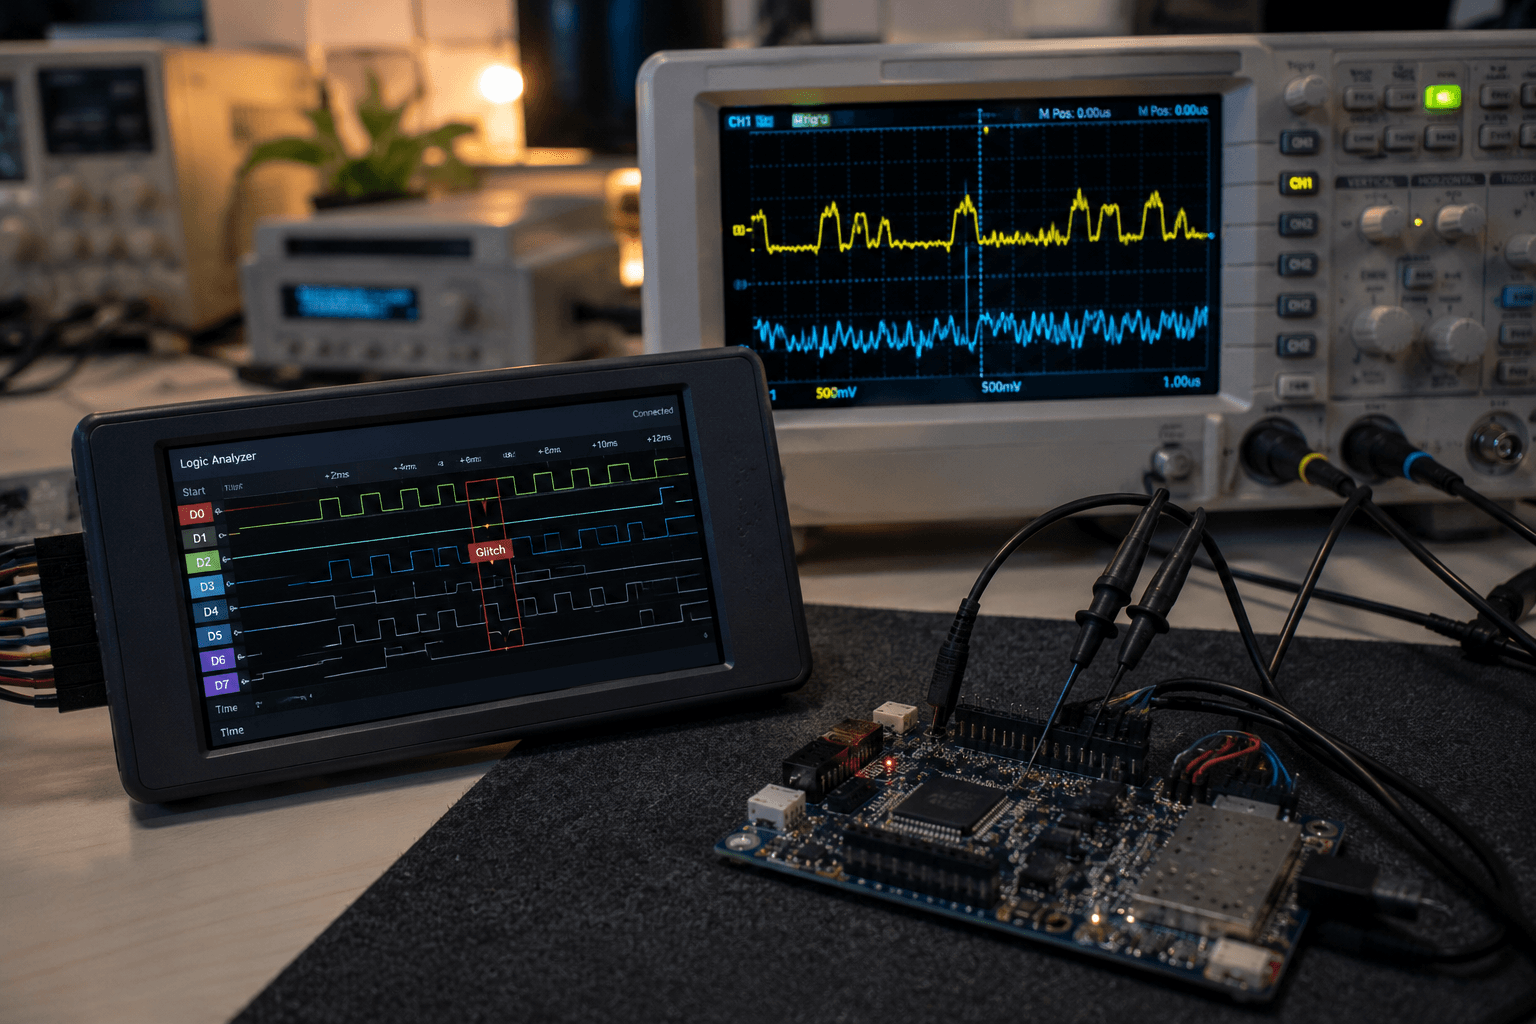
A three-week hunt through a race condition between an ISR and a flash write routine.