 BlinkThorLabs
Holding the RRC Lite Controller: A Hands-On Teardown
Not a datasheet. Just me, the board, and every little cluster of components I almost overlooked the first time.
Hoang connects simulation architecture, embedded software and the development workflows needed to build software-defined vehicle features. His background reaches from Linux/Qt systems and automotive telematics to CARLA, ROS 2, scenario execution and virtual-cockpit integration. As Principal Technical Lead, he helps turn a collection of tools into a coherent platform that engineers can use to develop, investigate and validate vehicle behavior.
Technical Lead, CARLA, ROS 2 and scenario workflows
His simulation-platform work includes architecture, scenario generation using OpenSCENARIO/OpenDRIVE, esmini integration and automation for execution, debugging and analysis. Virtual Cockpit and HMI integration connect the simulation with the behavior that an operator or driver sees. He also establishes CI/CD and quality workflows and mentors engineers in architecture, troubleshooting and the use of simulation as an engineering tool.
FPT Software, Technical leadership
Hoang has provided technical direction for an automotive emergency-call application, overseeing software quality, integration changes and troubleshooting. This experience links application-level features to the constraints and communication patterns of an embedded vehicle platform. It also informs how he structures work, reviews implementation decisions and coordinates a team around customer milestones.
Hitachi Vantara and FPT Software, Cross-platform delivery
Earlier technical-lead work includes new CCTV features, Qt and web interfaces, TCP/IP log-recording systems, industrial measurement applications and H.264/H.265 video-streaming software. These projects span C/C++, C#, databases, Windows and Linux application frameworks. They provide a broad foundation for simulation tools that need reliable data flows, clear interfaces and robust integration across multiple technologies.
His academic foundation is Computer Engineering at Can Tho University (2008–2012). He holds a Master’s degree in Computer Engineering. His professional history includes FPT Software and Hitachi Vantara Vietnam. Technical tools span C/C++, Python, Rust and C#, Linux/Qt, Docker, GitLab CI/CD, CARLA, ROS 2, esmini, OpenSCENARIO and OpenDRIVE.
Hoang is a fit for partners who need a simulation or SDV development platform that can grow with their engineering program. He can help define platform boundaries, select and integrate tools, establish scenario and result workflows, connect HMI applications and improve build/test automation. His role combines hands-on technical work with the coordination needed to make a platform usable by a wider team.
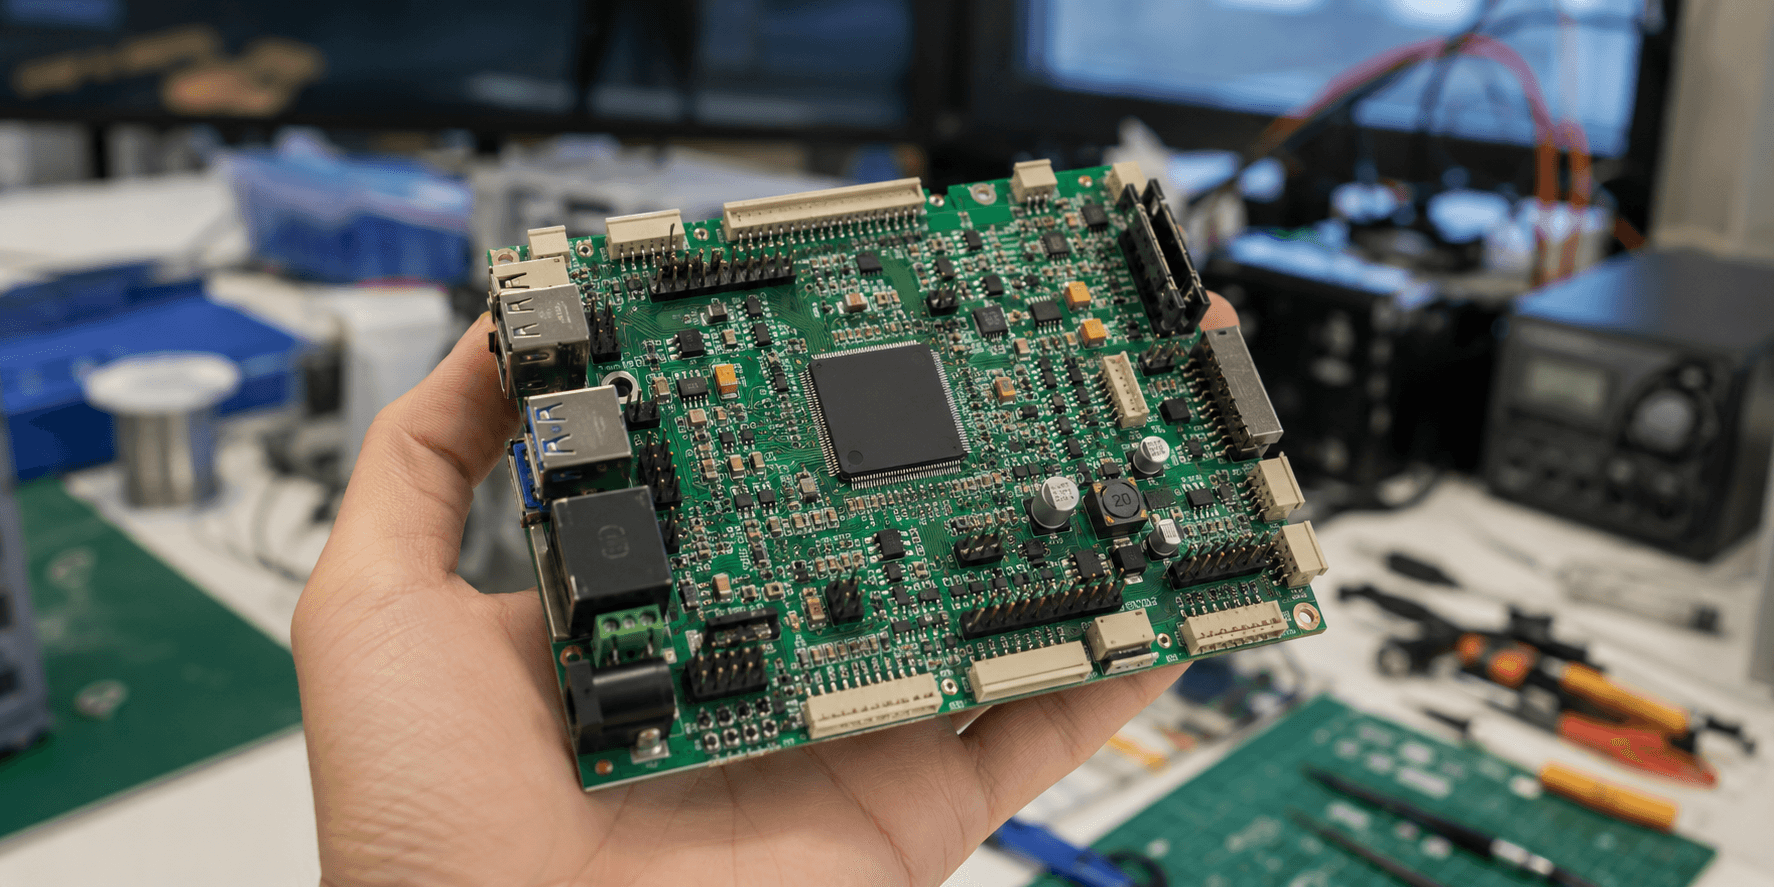
Not a datasheet. Just me, the board, and every little cluster of components I almost overlooked the first time.
Not a driver-facing FAQ. A corrective for the misconceptions that show up in our own sales decks first.
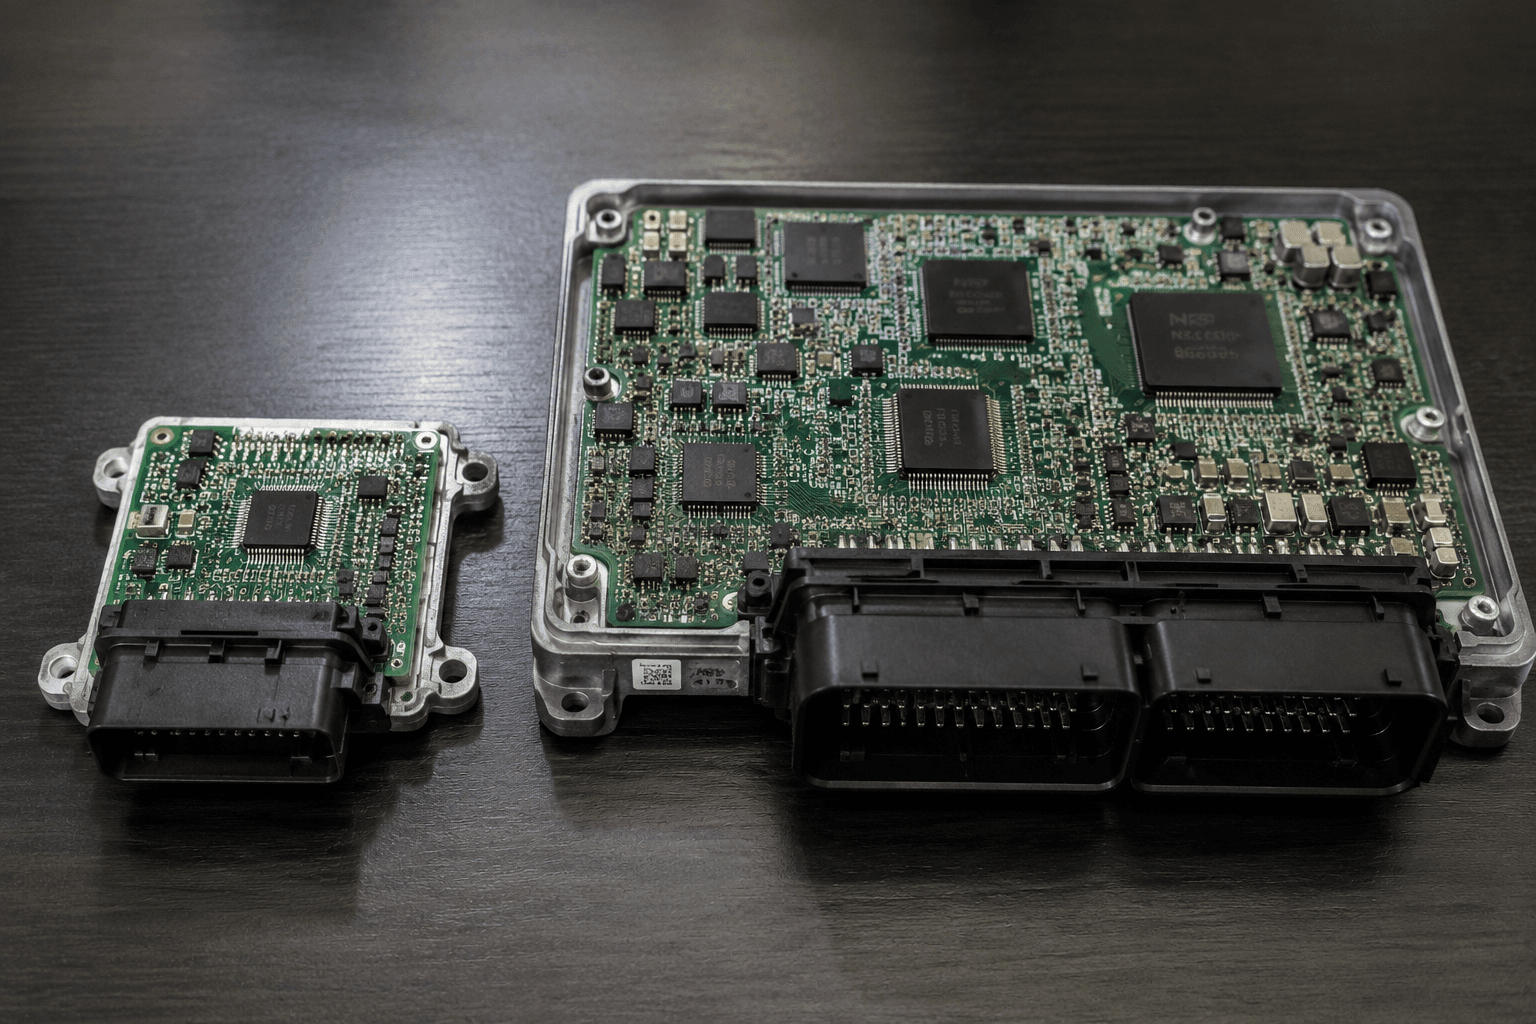
Every number on that page is true. Not all of them are true in the way you're about to assume.
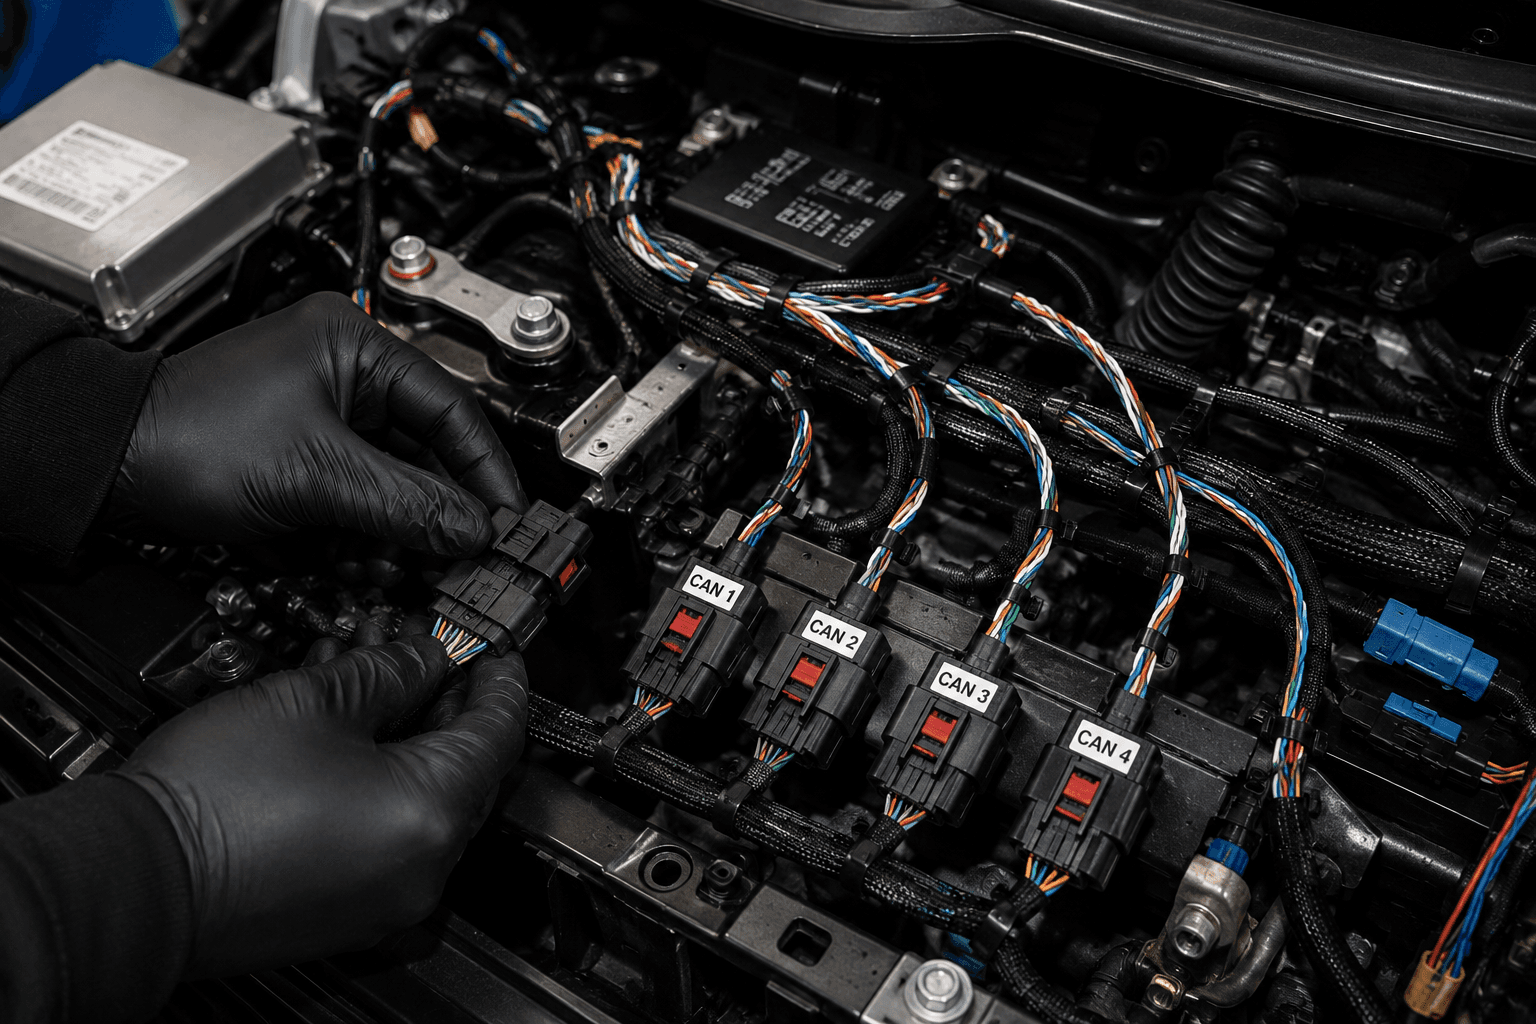
Sample points, propagation delay, and how one oscillator tolerance broke a whole harness.