 BlinkThorLabs
An Afternoon Skipping ROS2 Entirely to Talk to the Board in Raw Hex
No launch files, no nodes, no topics. Just a Type-C cable, a serial terminal, and every byte typed by hand.
Nguyen works at the intersection of ADAS feature development, automotive software verification and software-defined vehicle simulation. His experience combines camera/radar software, AUTOSAR integration, requirements-based testing and tools that help engineers inspect a simulation. As Senior ADAS & SDV Software Engineer, he brings a practical development-and-verification perspective to features that need to work across algorithms, software platforms and vehicle interfaces.
FPT Software, CARLA and Eclipse Velocitas
His work includes configuring CARLA scenarios, applying Eclipse Velocitas to vehicle applications and supporting web interfaces for simulation visualization and interaction. The technical scope brings together Python, C++, vehicle-signal concepts and application tooling. It supports a development workflow in which a team can exercise a feature, inspect its behavior and investigate an integration issue without relying on a physical vehicle for every iteration.
Automotive platform programs, Unit and integration testing
Trong has analyzed AUTOSAR requirements and architecture, configured BSW/OS modules and developed unit and integration tests. His experience includes VectorCAST, Codebeamer traceability and automotive testing principles. He connects a requirement to testable software behavior and helps investigate the gaps between a configuration, a generated platform and the implementation running on a target.
Radar ADAS programs and advanced capability development
Earlier radar work includes requirements analysis, GoogleTest/Cantata test scripts and host/target framework investigations using MSVC, GHS and TRACE32. His ADAS development background includes MATLAB/Simulink scenario work and lane, following-distance, cruise-control and braking functions. Additional projects cover telematics/eCall, MQTT and embedded prototypes, giving context to the communication and tooling surrounding a vehicle feature.
His academic foundation is Electronics and Telecommunication Engineering at Can Tho University (2018–2022). His technical work spans embedded C/C++, Python and application tooling, with platforms including S32K144, S32G and TC39x families. His engineering toolset includes GoogleTest, Cantata, VectorCAST, CARLA, Eclipse Velocitas, MATLAB/Simulink, Git and requirements-management tools.
Trong can contribute to an ADAS or SDV workstream through feature implementation, simulation setup, verification, visualization tools and integration investigation. He is particularly useful where algorithm development and software testing need to stay connected. The collaboration can include reproducible scenarios, host/target test environments, traceable checks and tooling that helps the wider team understand the feature.
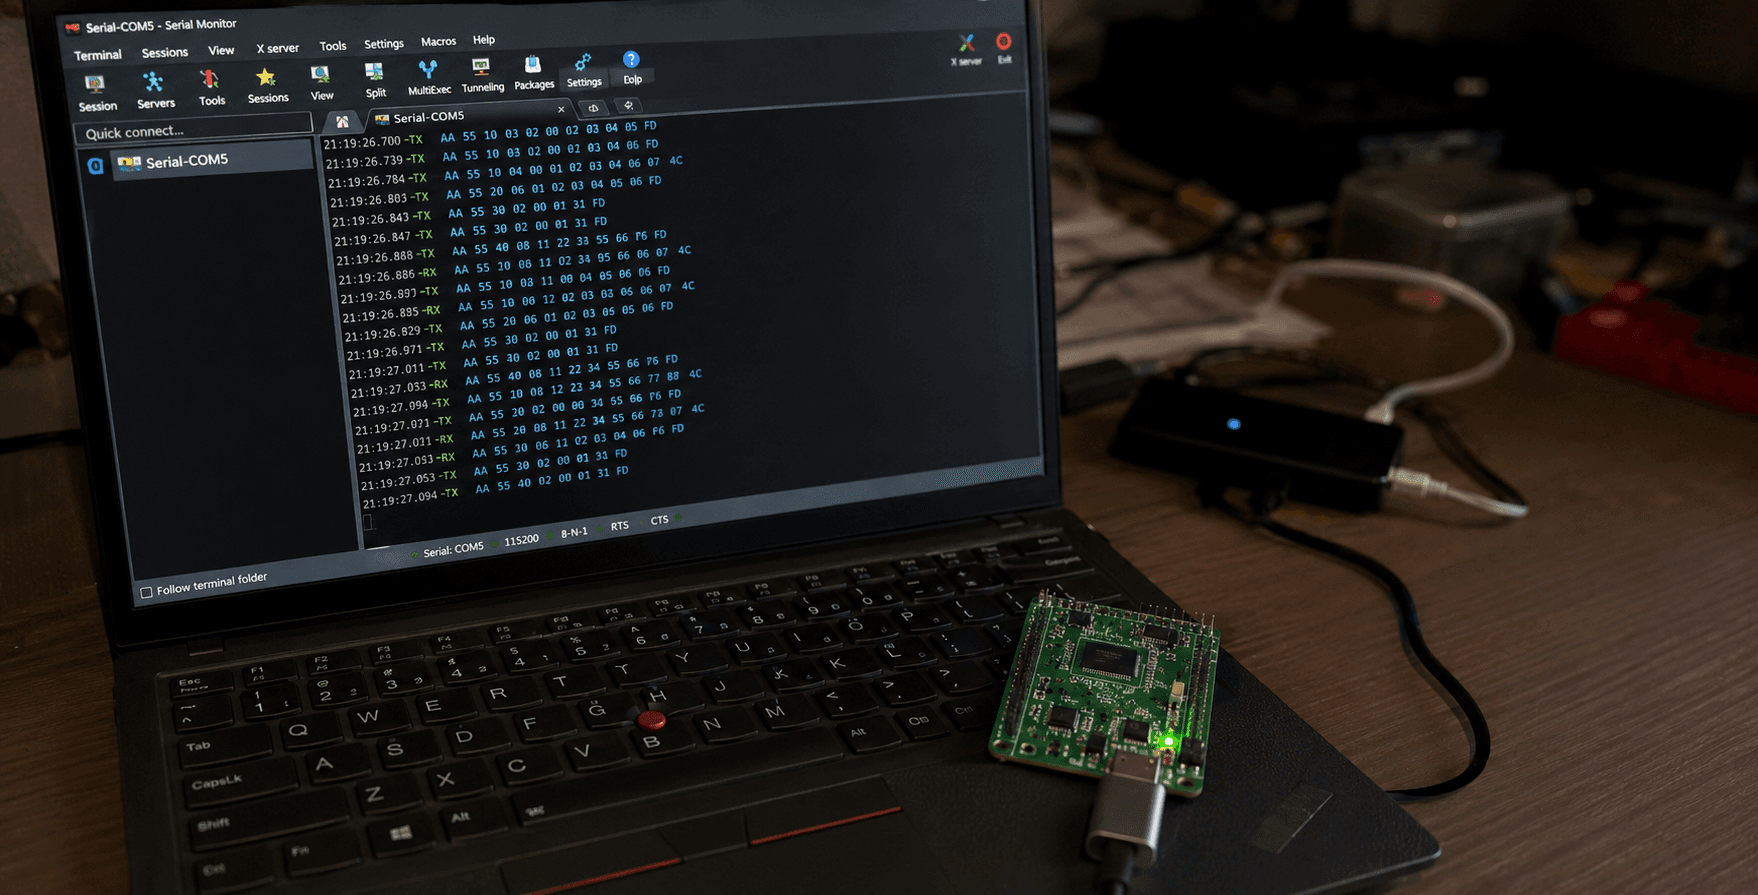
No launch files, no nodes, no topics. Just a Type-C cable, a serial terminal, and every byte typed by hand.
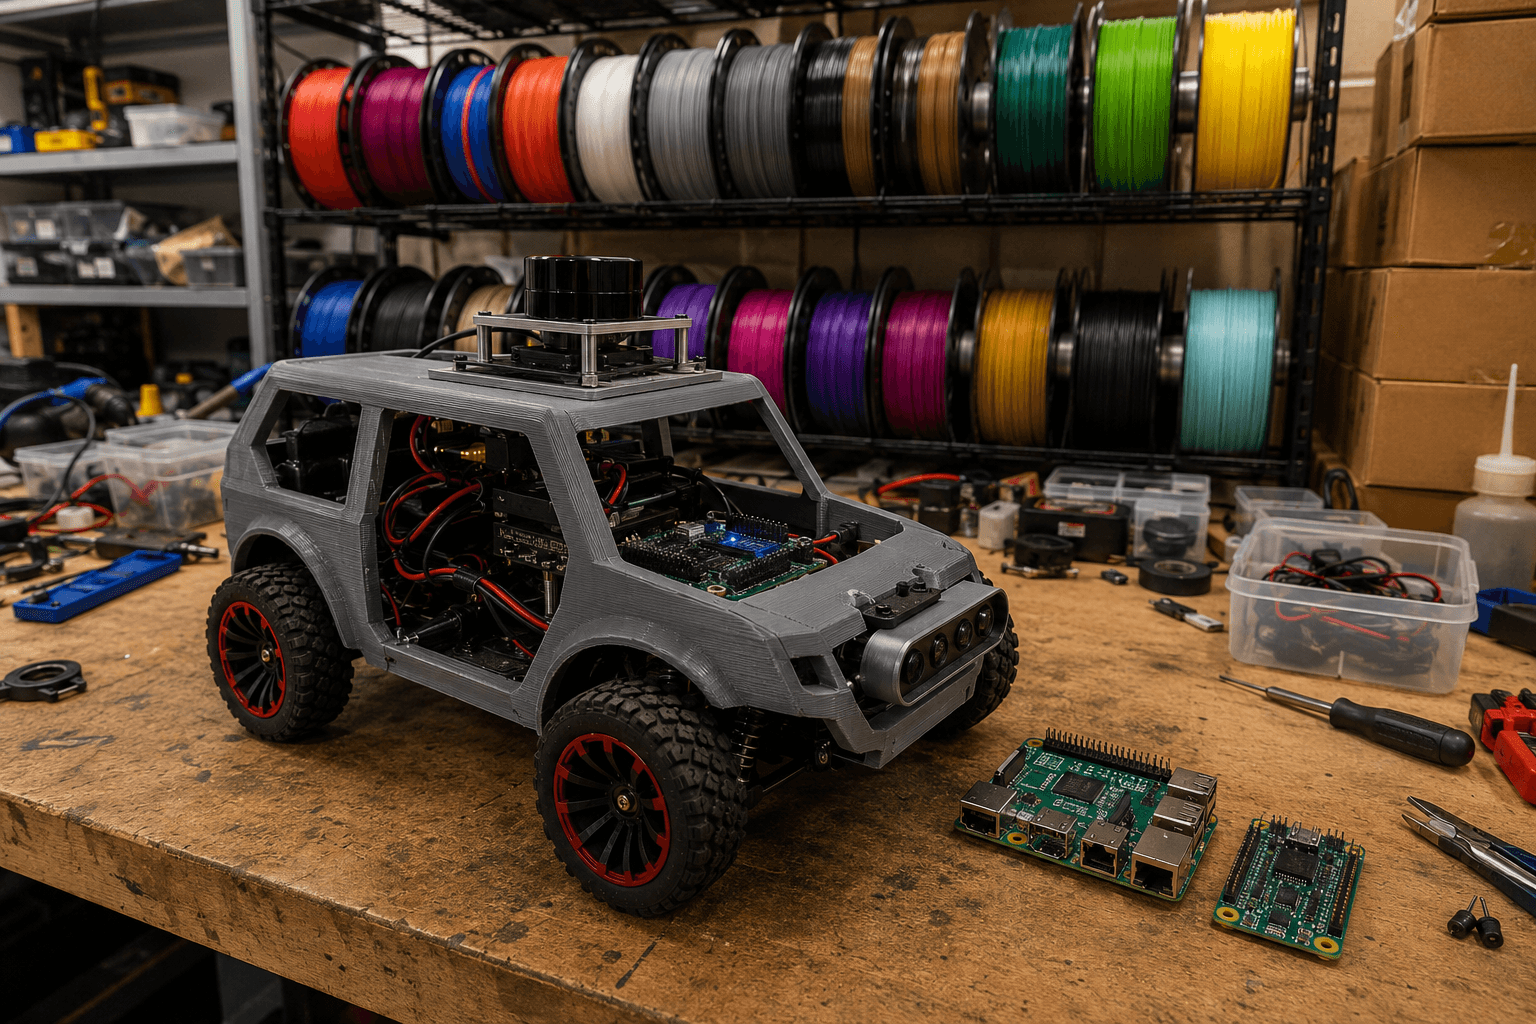
Ackermann chassis, ROS2 on a Raspberry Pi 5, and the specific joy of hearing a buzzer confirm your first boot actually worked.
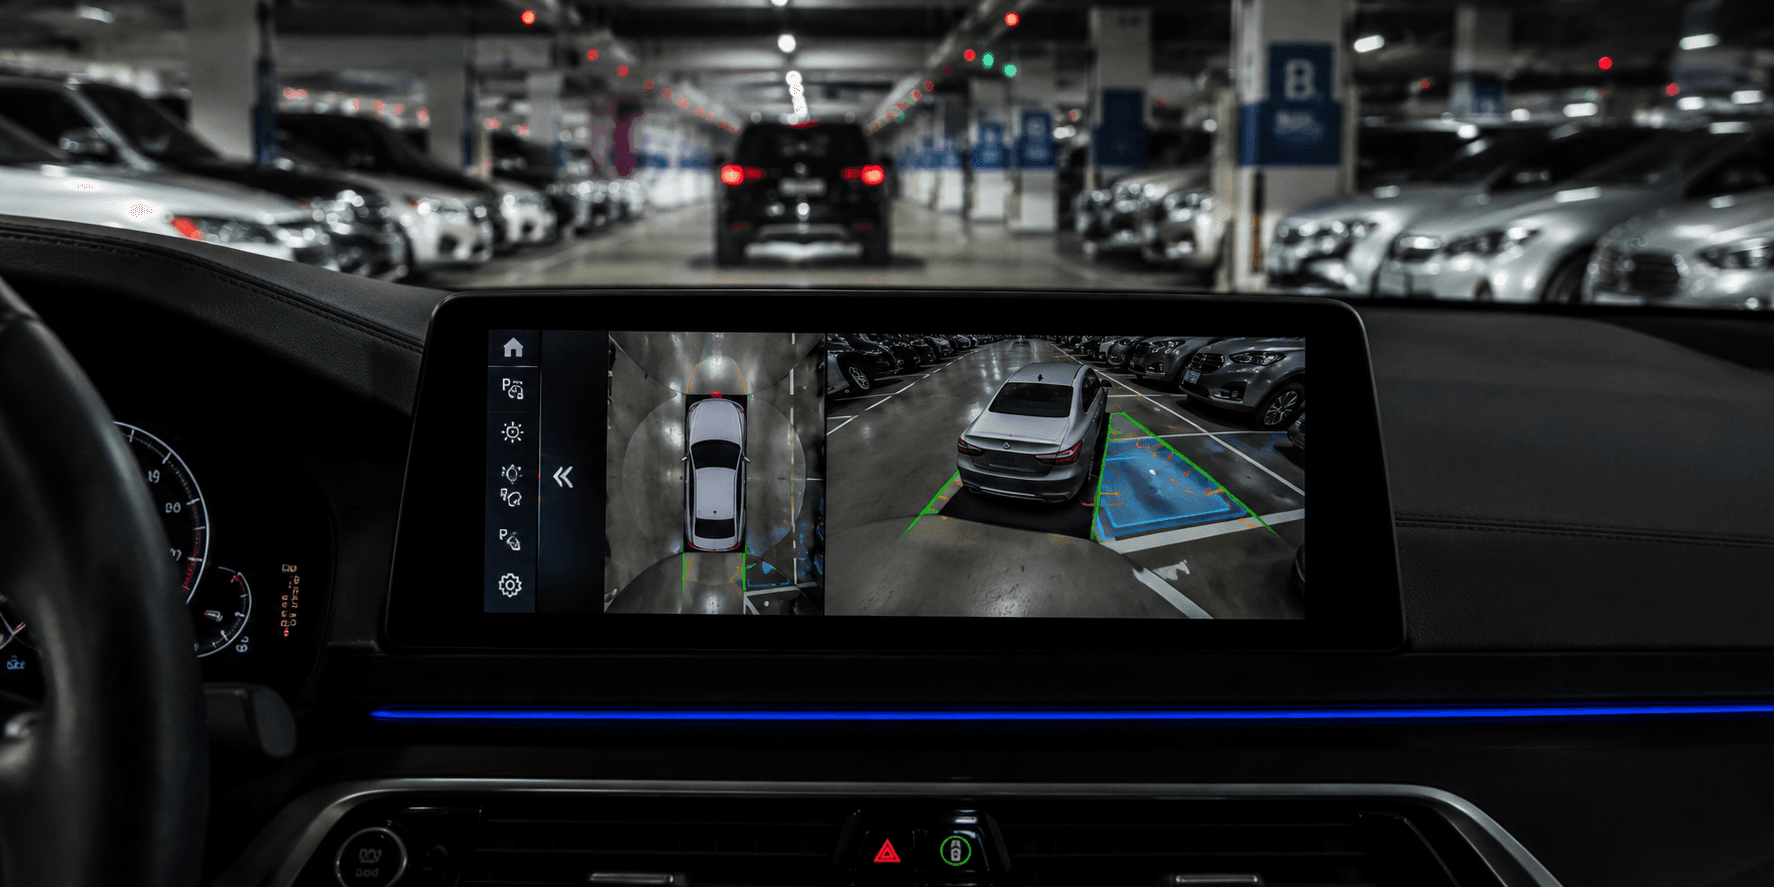
The trajectory math was solved decades ago. Here's where the actual engineering effort goes instead.
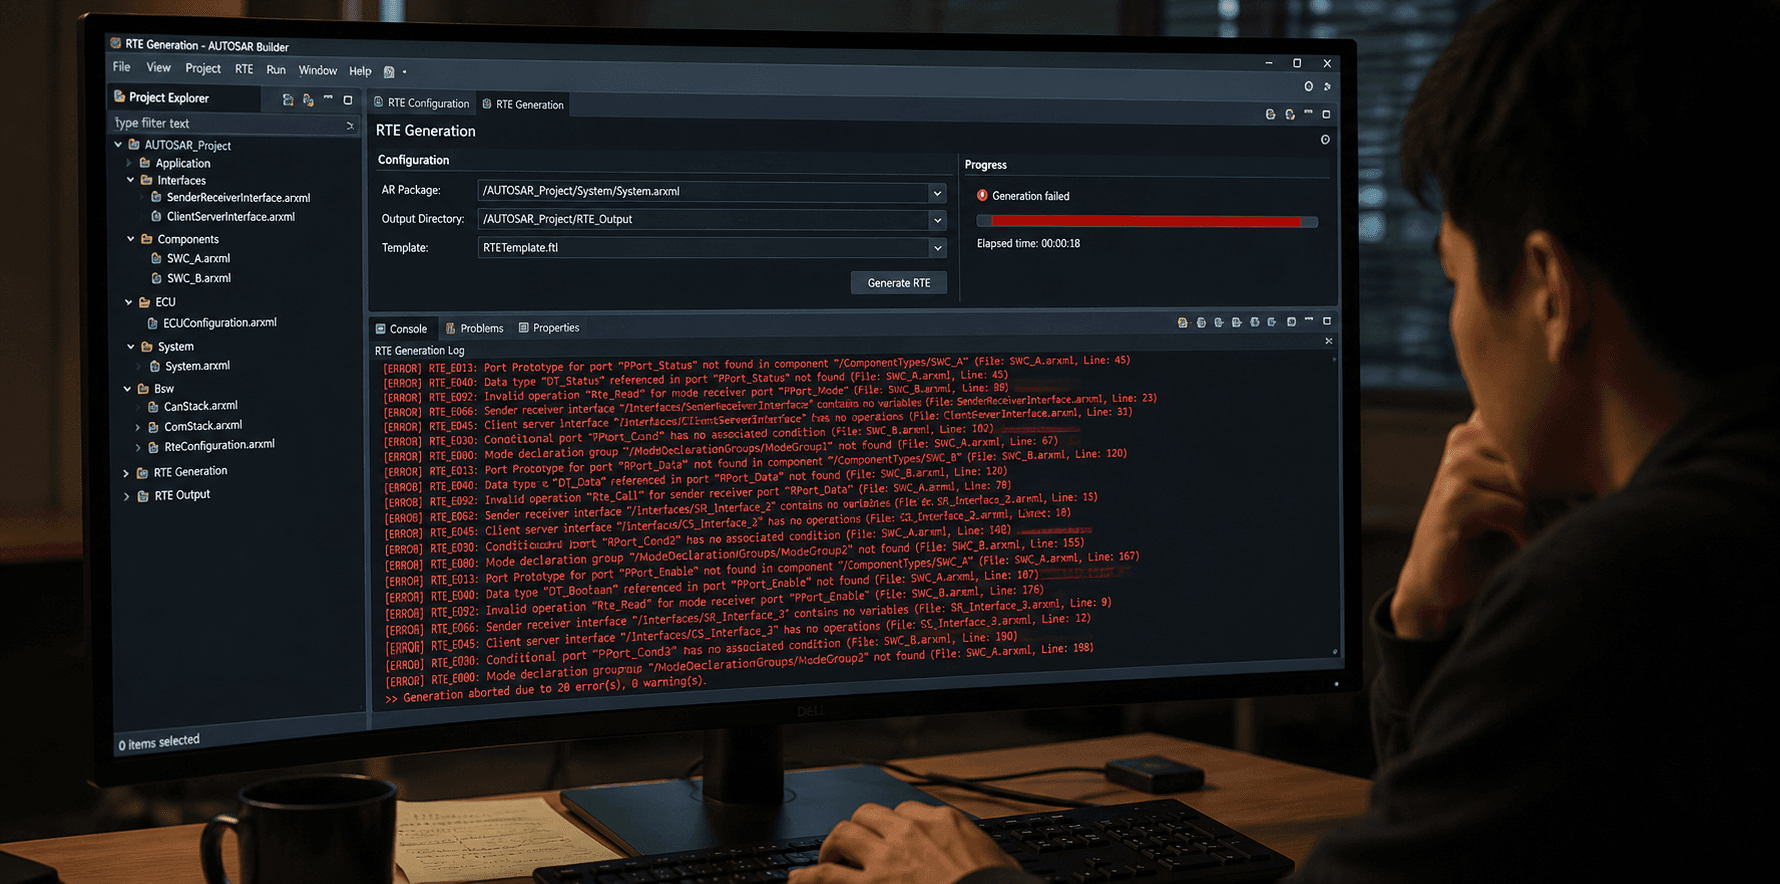
Eight error messages, translated. No preamble — you have a build failing right now.
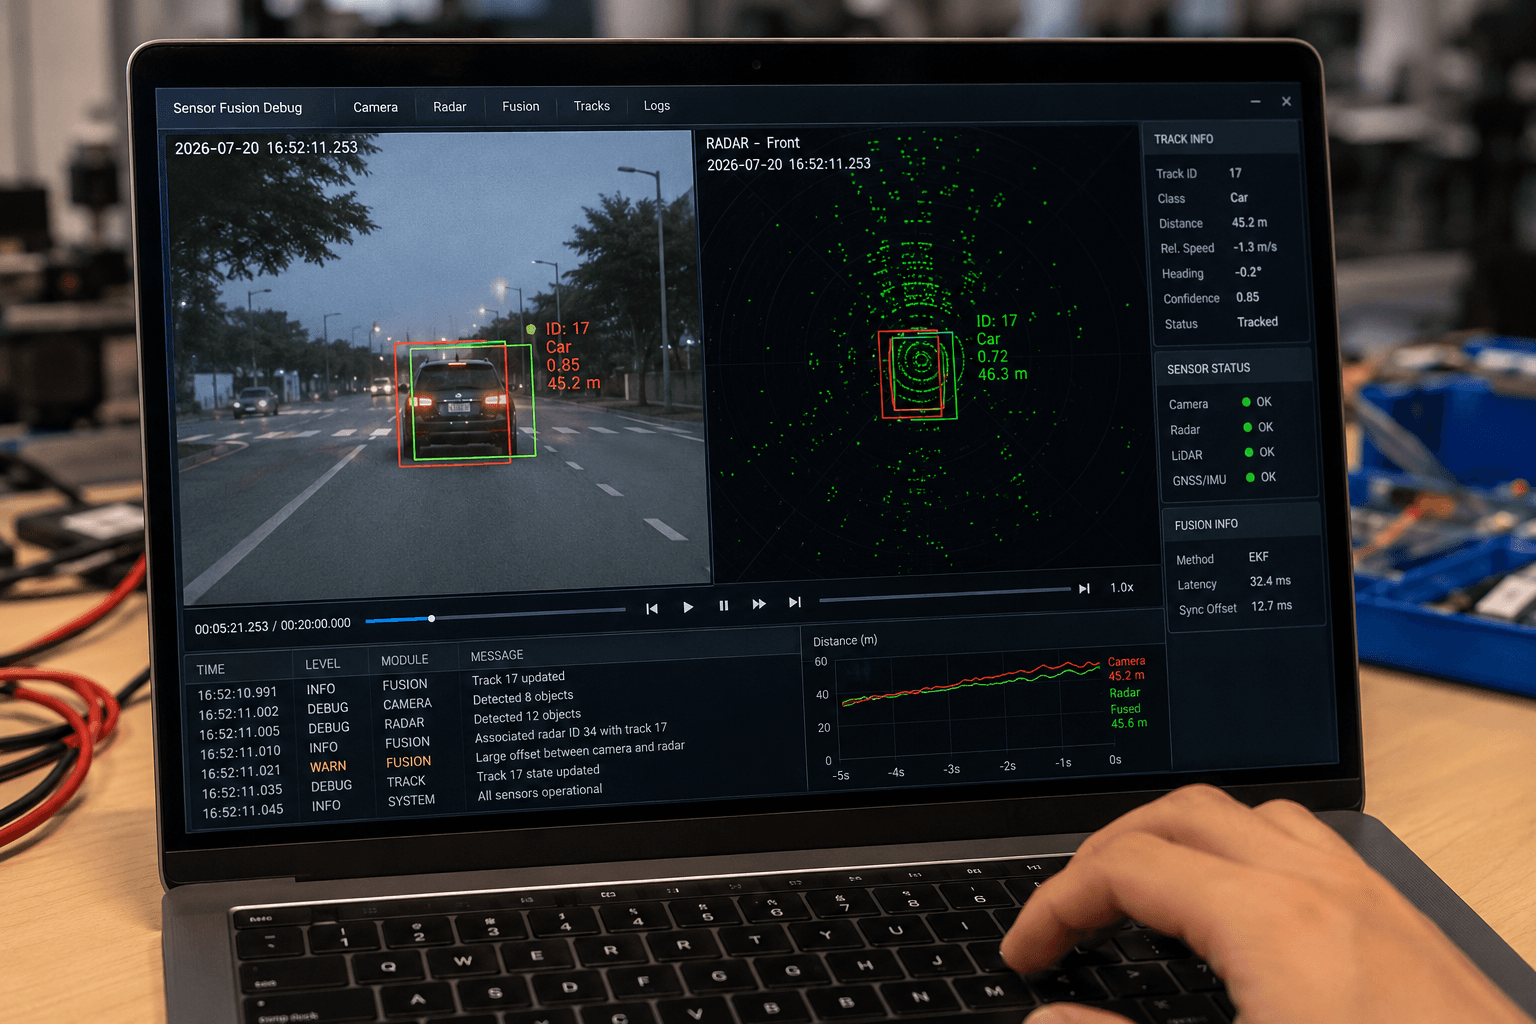
A missed PTP correction cost four car-lengths of tracking error at speed.
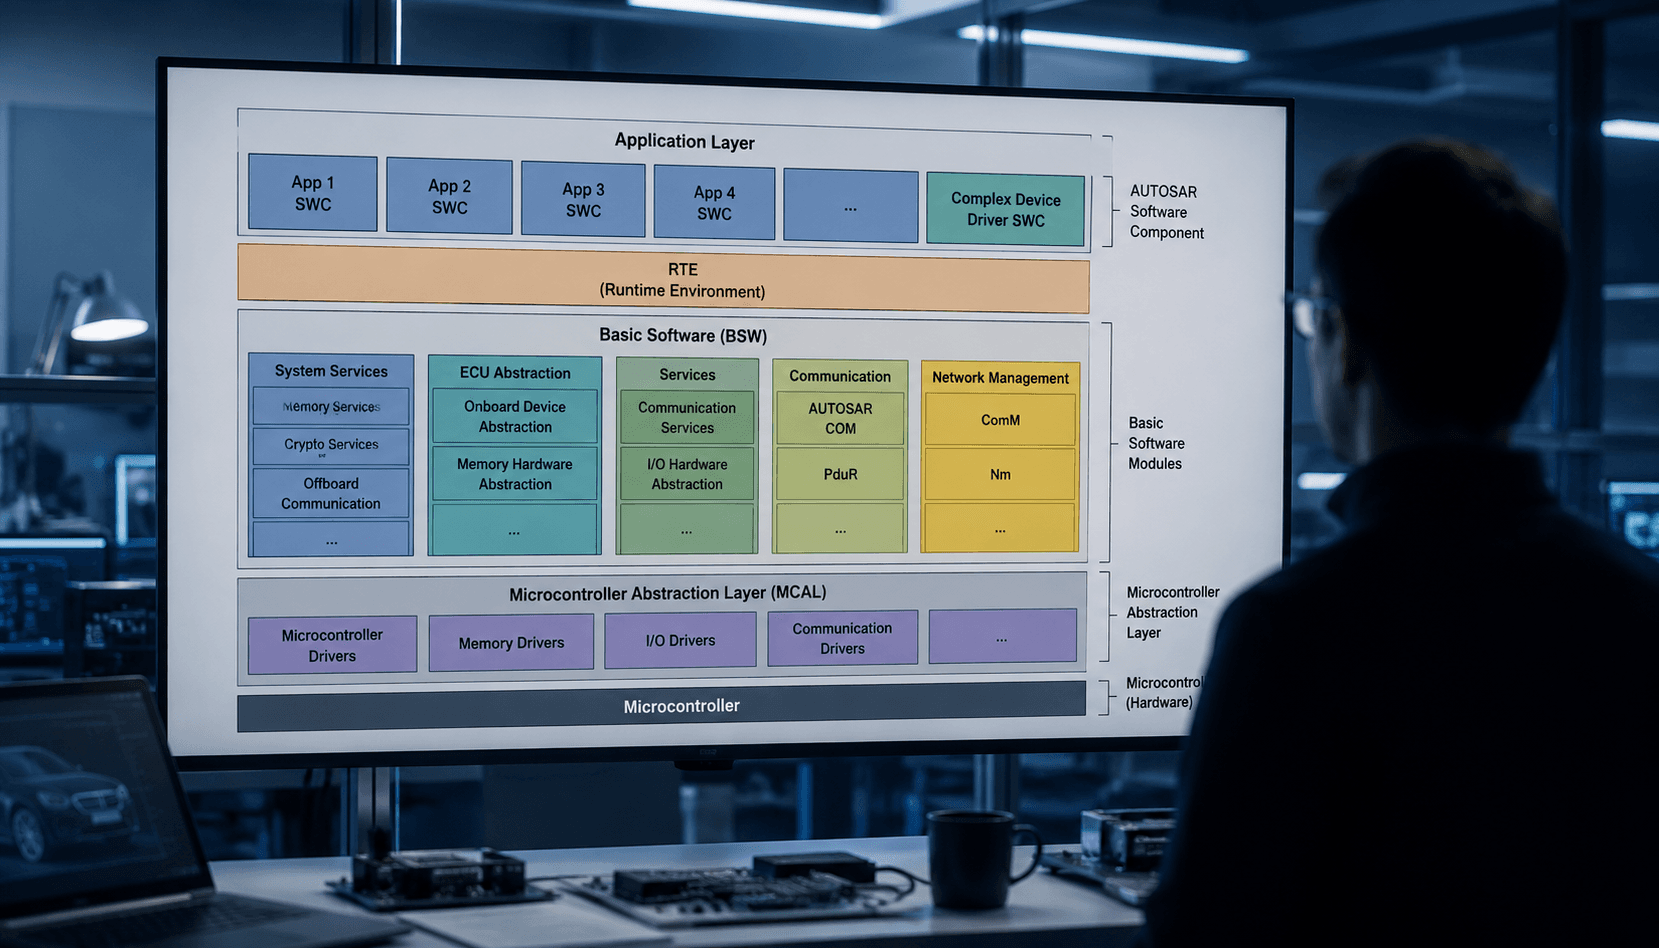
Six milestones, realistic time estimates, and the mistakes everyone makes at each one.