 BlinkThorLabs
A Weekend Teaching MentorPi to Read Traffic Signs
Saturday's first bounding box, Saturday afternoon's confidence-threshold headache, and the Sunday moment every piece finally clicked into place together.
Nhan combines automotive ECU software, verification automation and the emerging software-defined vehicle stack. His experience spans AUTOSAR Classic, thermal-management controllers, radar testing, ROS 2 simulation and camera/LiDAR perception workflows. As Senior ADAS & SDV Software Engineer, he connects established automotive delivery practices with the software, data and interfaces needed for new vehicle applications.
FPT Software, HVAC ECU development
His ECU work includes embedded application software for cabin temperature, blower behavior, actuator positioning and compressor communication. Verification covers CAN/LIN signals, UDS diagnostic services, DTC handling and routines, along with target debugging and integration testing. This provides practical experience with vehicle-controller behavior, communication and the disciplined development process around automotive software.
FPT Software, CARLA, ROS 2, VSS and Unity
Nhan has built bidirectional SDV communication pipelines, synchronized camera/LiDAR data workflows and simulation interfaces for vehicle functions. His experience includes YOLOv8/PointPillars training and evaluation, perception outputs on ROS 2 topics, HMI warnings and gateway nodes connecting application controls to simulated vehicle behavior. This scope links sensor data, AI outputs and the user-visible behavior of an ADAS feature.
FPT Software, Platform testing and automated delivery
His work spans test specifications, requirements traceability, CAPL rest-of-bus tests, host/target build environments and memory-crash investigations with TRACE32. Radar programs include Jenkins/Bitbucket pipelines, internal Python/Groovy tools, regression execution and automated quality reporting. Earlier embedded-test work at GESVN includes WinAMS, C-based tests, documentation automation and training for new verification engineers.
Nhan’s academic background includes Electronics and Telecommunications Engineering at Ho Chi Minh City University of Technology and Education, completed in 2019. His toolset spans C/C++, Python, CAPL, Bash and Groovy, AUTOSAR Classic, CAN/LIN/UDS, CARLA/ROS 2, CI/CD systems and host/target verification tools. His professional background includes FPT Software and Global Embedded Solutions Vietnam.
Nhan can support partners on ECU software, SDV applications and ADAS integration with a strong emphasis on reproducibility and verification. An engagement can combine software implementation, requirements/test traceability, automated pipelines, vehicle-signal integration and perception-data workflows. He helps connect the feature a team wants to build with the environments and checks required to develop it reliably.
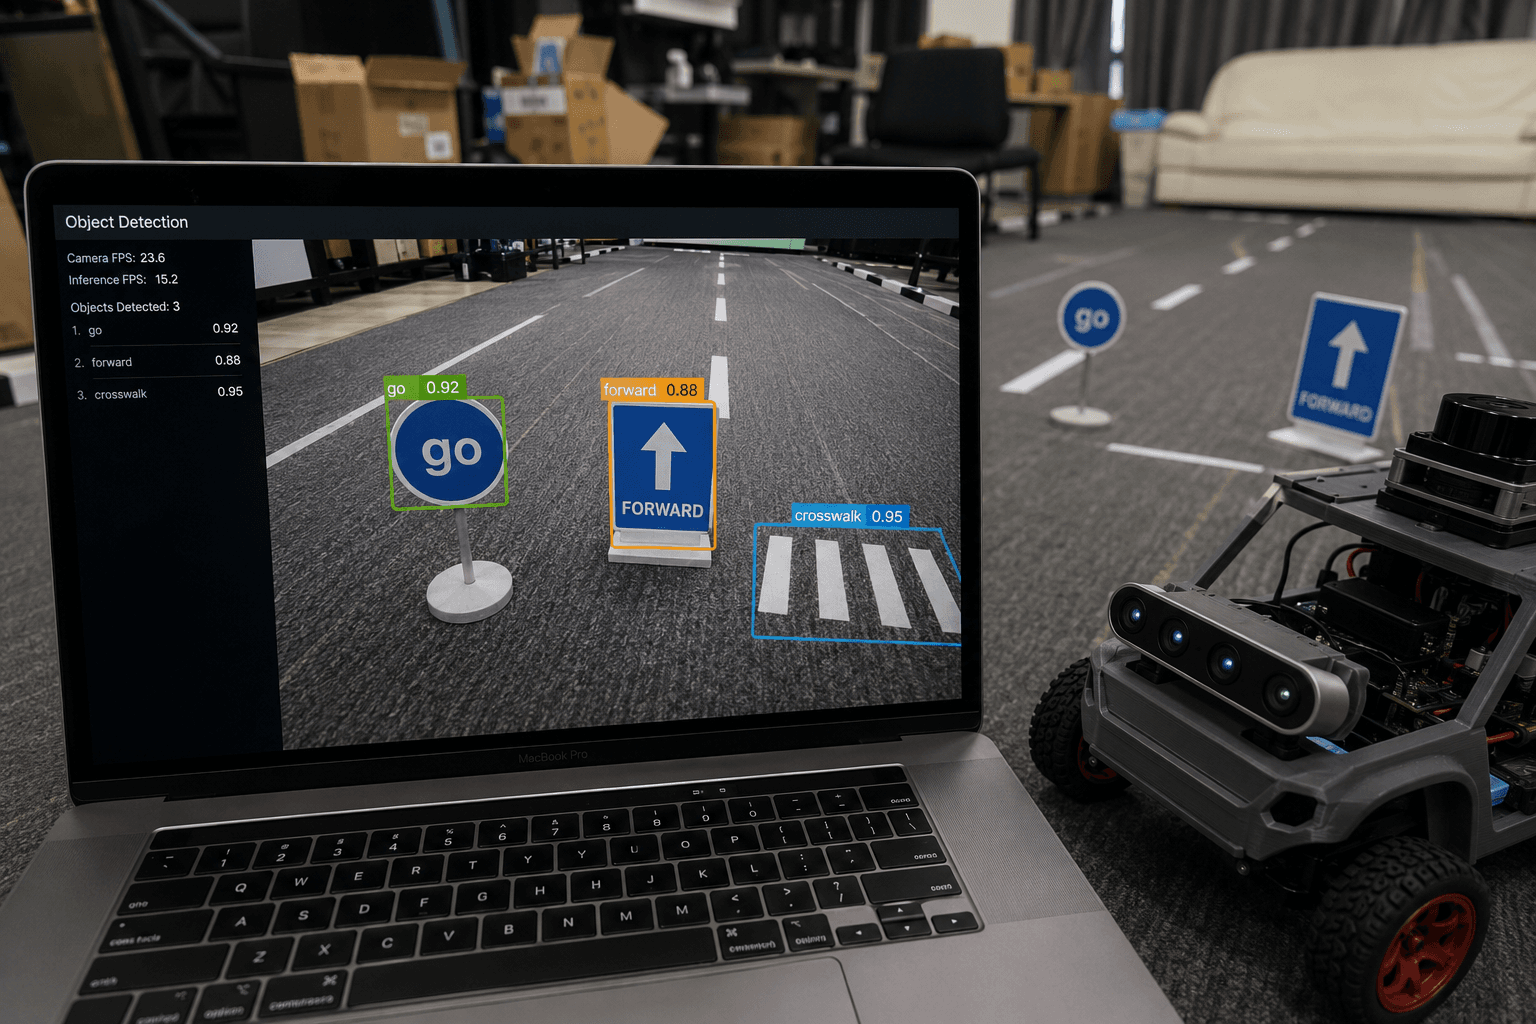
Saturday's first bounding box, Saturday afternoon's confidence-threshold headache, and the Sunday moment every piece finally clicked into place together.
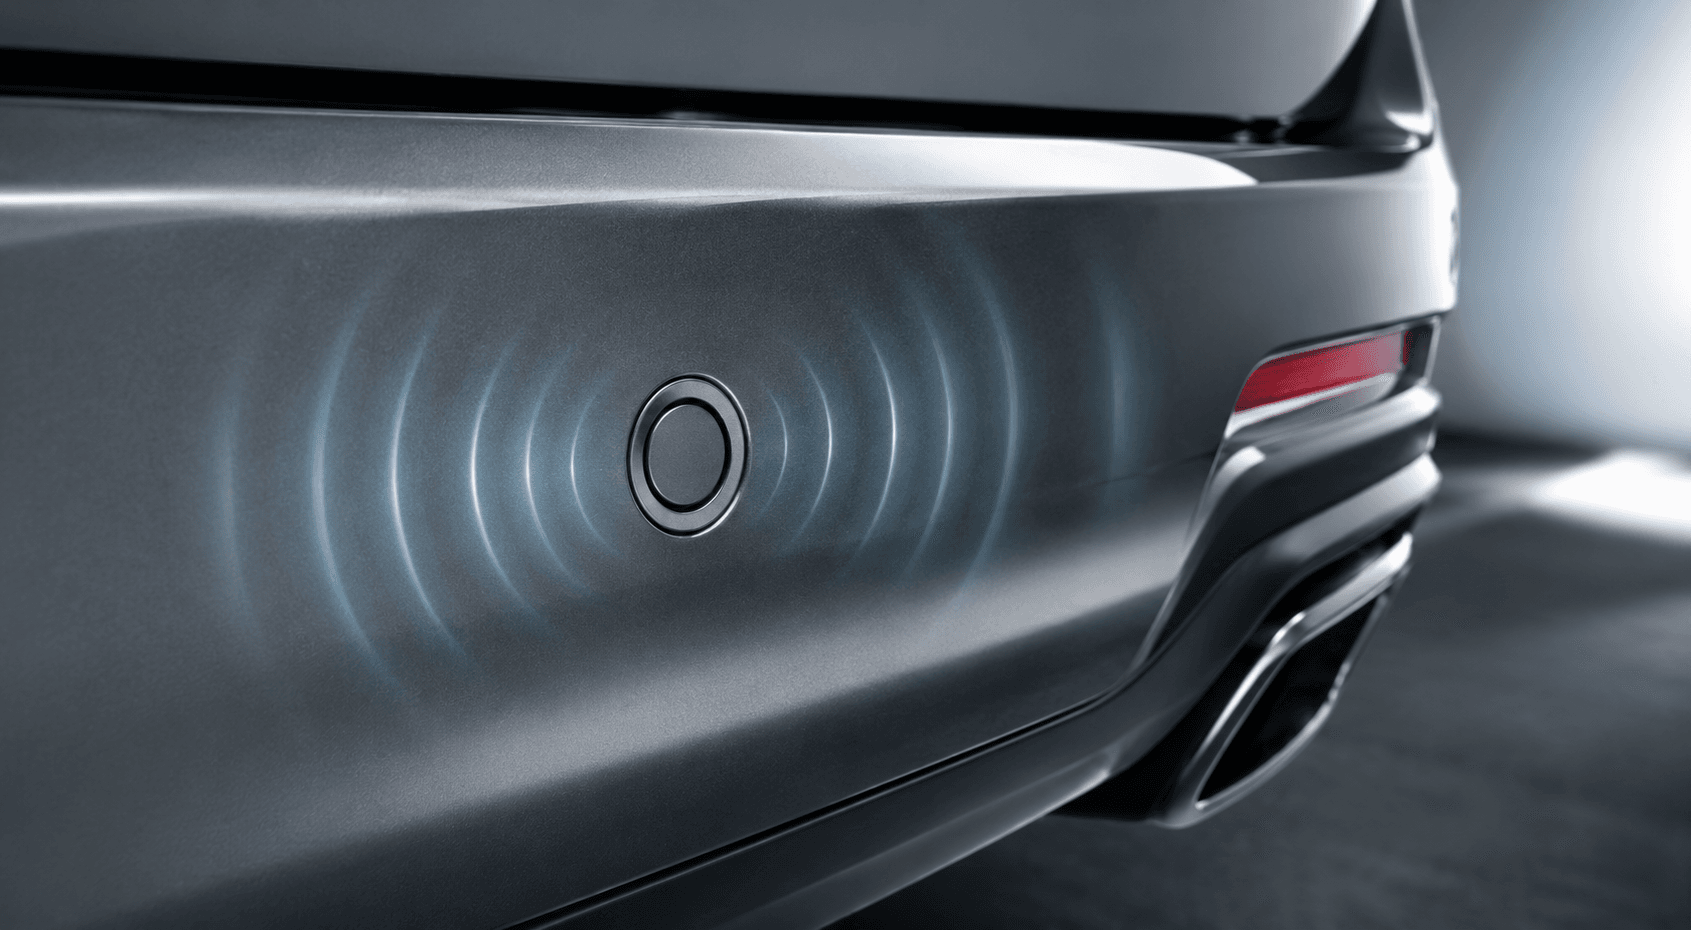
It's an echo. That's the whole idea. Here's where the idea quietly breaks.
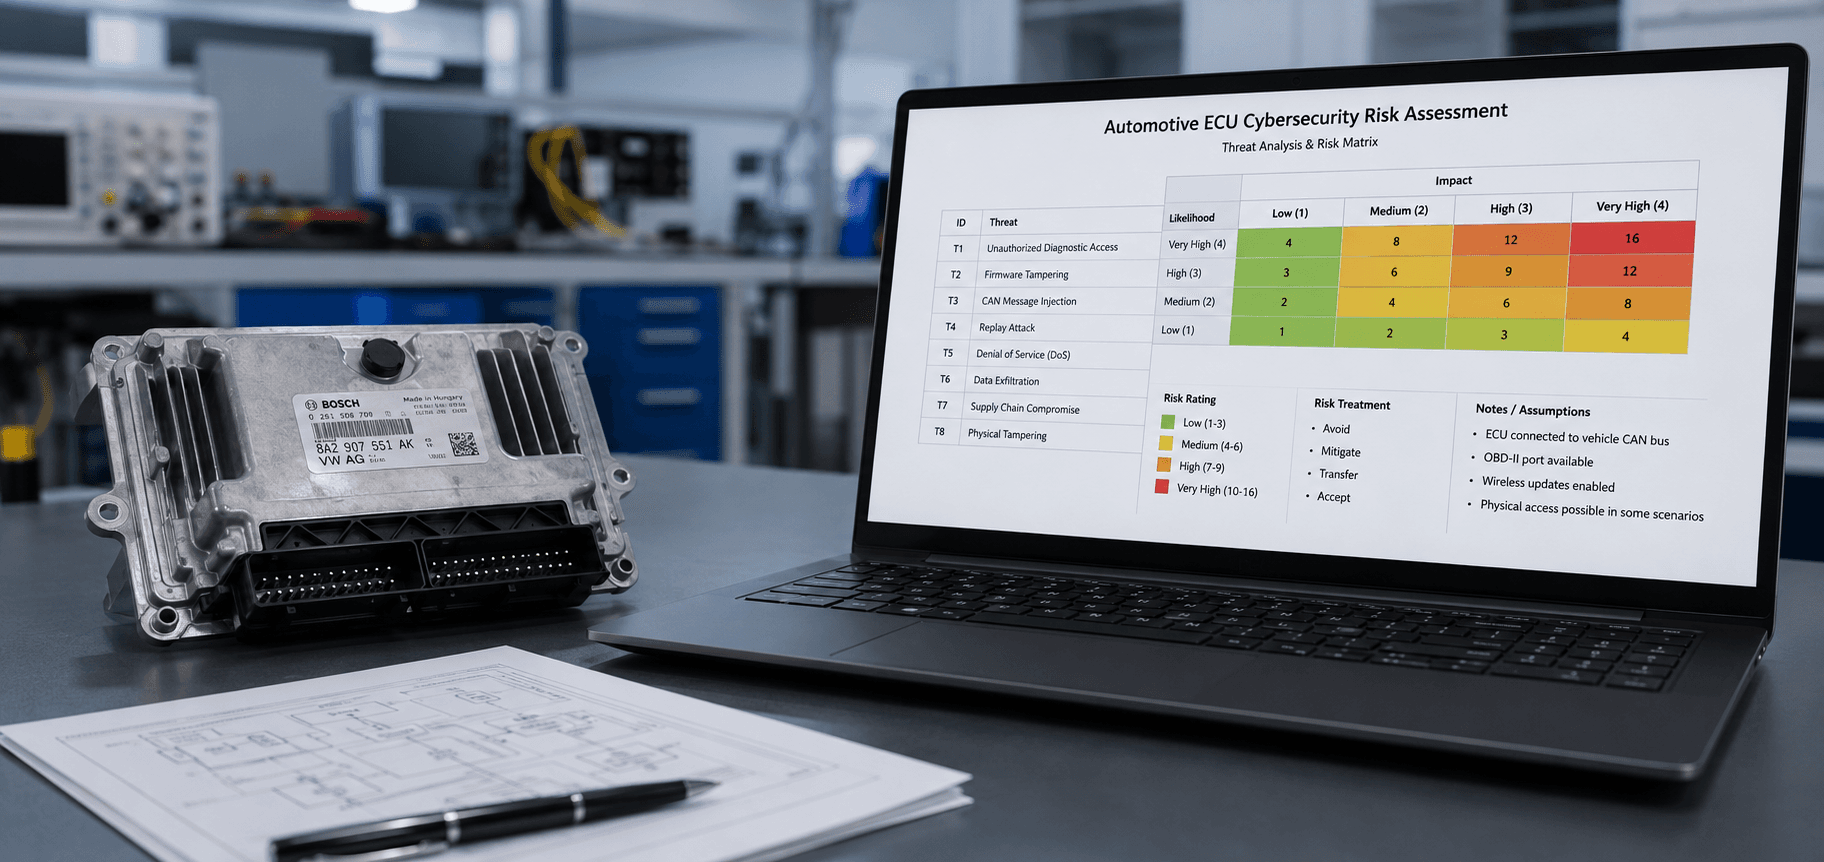
A translation guide, not a summary of the standard. Here's what each term actually means for your Tuesday.
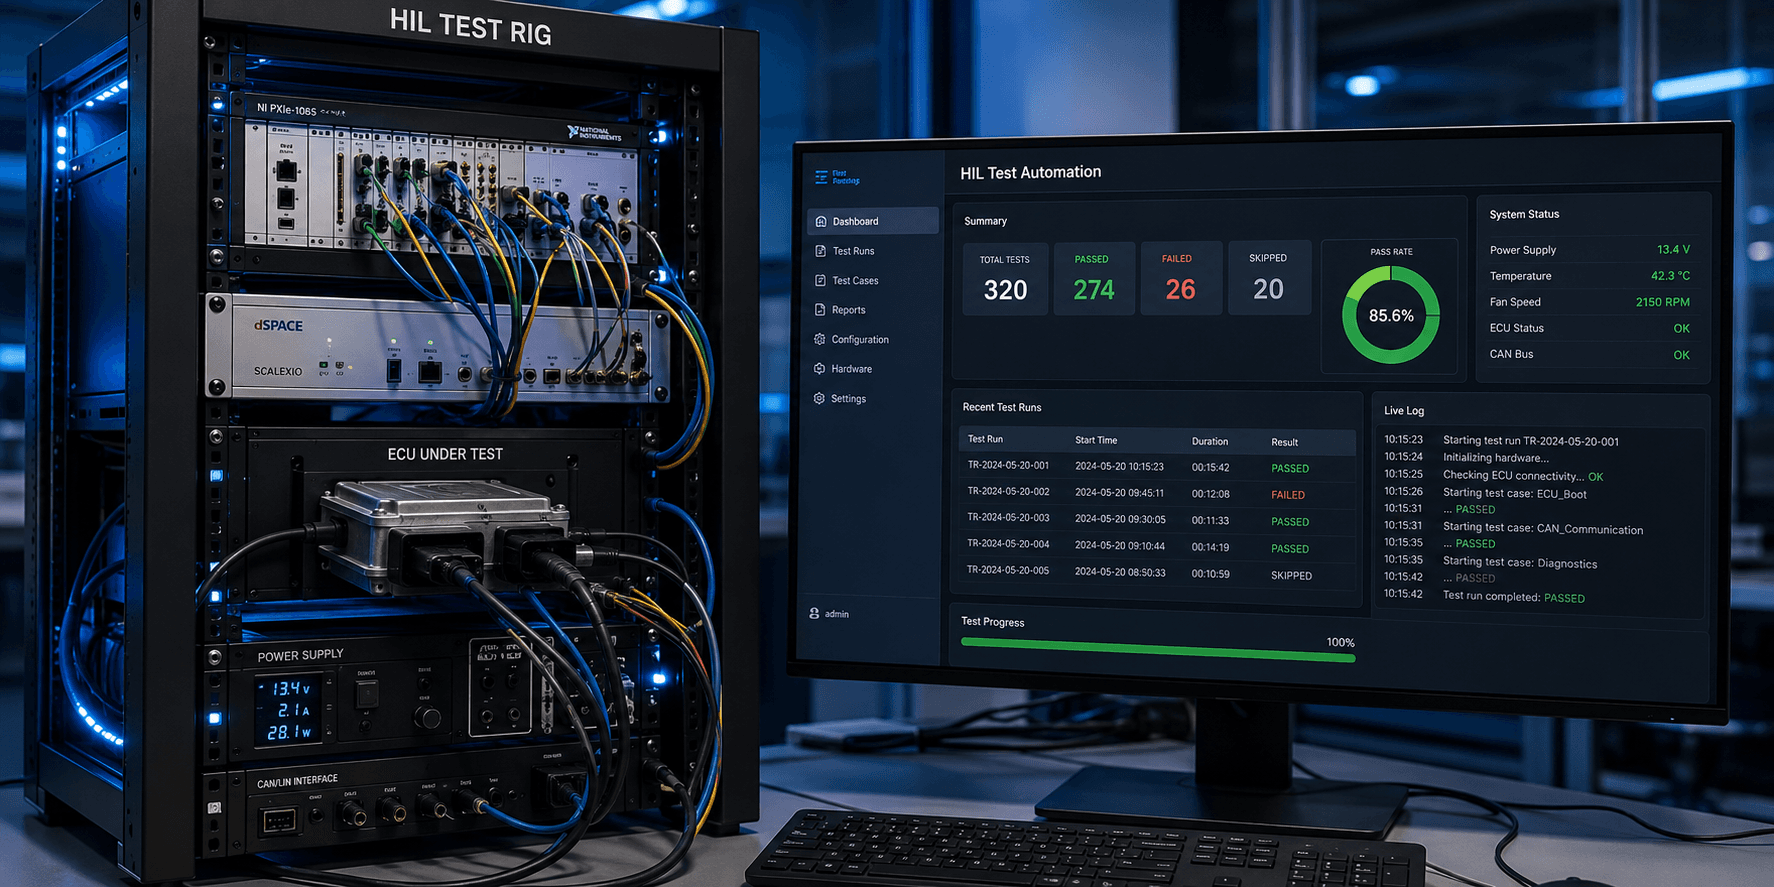
A practical retrospective on what went well, what didn't, and what we only found because we went looking.
Think like the attacker for a minute. Then build the bootloader that makes their plan pointless.
Priority inheritance is not automatic. Three real incidents and how we caught them.