 BlinkThorLabs
What We Actually Look For When Hiring an Embedded Automotive Engineer
A candid Q&A with one of our senior engineering leads, who's sat on the other side of this table more times than he can count.
Kien connects perception software with the embedded target and verification workflow that make it useful in an ADAS system. His experience includes camera/radar programs, GPU-to-ECU porting, requirement analysis, host/target testing and CI/CD automation. As Senior ADAS Perception Engineer, he brings an end-to-end view of a perception feature: the model and input data, the target integration, the interpretation of its outputs and the evidence needed to investigate differences.
FPT Software, Japanese automotive camera programs
His camera-platform work includes analyzing recognition specifications, adapting software and configuration to a target ECU and investigating host/target behavior. Responsibilities span model binaries, dictionaries, scheduler integration, communication interfaces, release branches and frame analysis. He has also developed Python and Excel-VBA tooling for consolidated diff reports and authored technical documentation across Japanese, English and Vietnamese workflows.
FPT Software, Automotive CI/CD and verification
Kien has built and maintained build/test pipelines and host/target unit and integration-test environments using tools such as Bitbucket Pipelines, Cantata, GoogleTest, Squish Coco, TRACE32, GHS and MSVC. His work covers requirement-based specifications, regression execution, coverage analysis and defect investigation. This helps connect perception development with a repeatable delivery and review process.
Independent engineering project, Perception, control and firmware
His portfolio includes a 1/10-scale vehicle prototype spanning lane and object perception, behavior rules, PID-based vehicle control, ESP32-S3/FreeRTOS firmware, UDP telemetry and a PC-based HMI. The work also includes Raspberry Pi camera streaming, safety logic, watchdog behavior and sensor feedback. It provides direct integration experience across the boundary between an AI pipeline and a moving physical platform.
My Lan Group and TrueCommerce Vietnam
Earlier work includes firmware for industrial packaging and vending systems, peripheral integration, operating-state machines and hardware/software debugging. His data-integration experience includes EDI/XML/CSV mappings, validation rules and the investigation of input/output defects. These projects strengthen his attention to interfaces, data consistency and reliable behavior across system boundaries.
Kien holds a B.Eng. in Mechatronics Engineering at Can Tho University of Technology (2017–2021). His technical practice includes C/C++, Python, OpenCV, PyTorch, YOLO, UFLD/ParsingNet, TensorRT/CUDA, embedded firmware and real-time communication. Language capability is recorded as native Vietnamese and professional working English.
Kien can help partners bring a perception feature from an offline environment into an embedded system, investigate target differences and create an effective validation and automation workflow. Engagements can combine model/configuration porting, input/output inspection, ECU integration, regression tests and engineering tools. His prototype experience also supports discussions about the interaction between perception, vehicle behavior, control and operational safety.
A candid Q&A with one of our senior engineering leads, who's sat on the other side of this table more times than he can count.
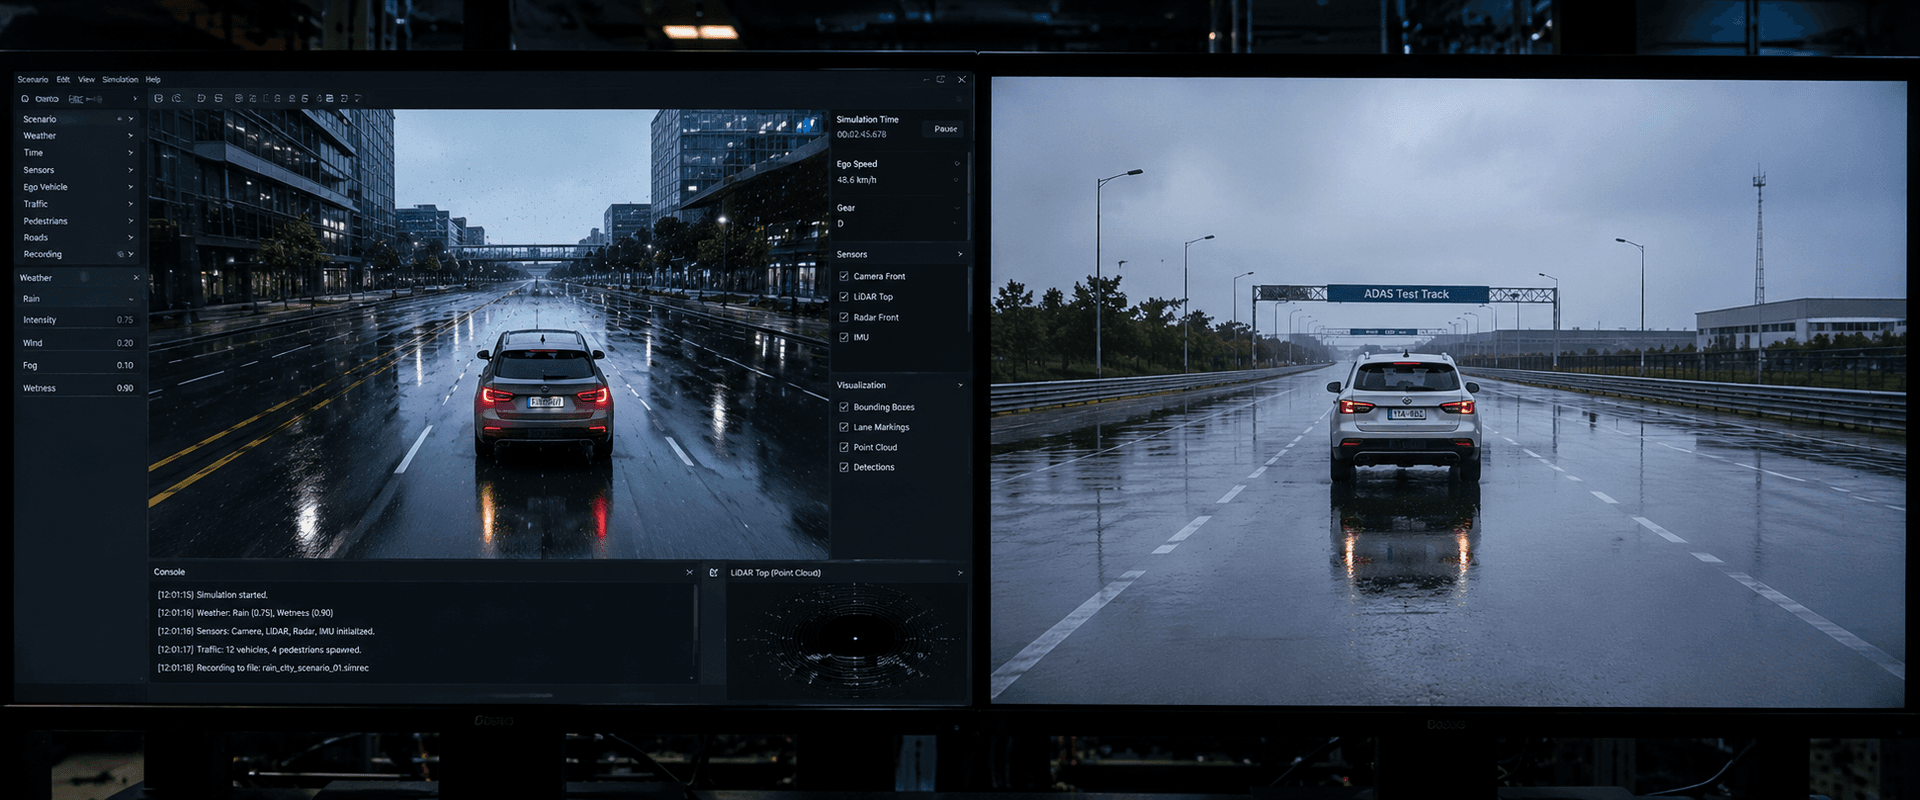
Six weeks of validation numbers told us we'd solved rain. They were answering a different question than the one we asked.
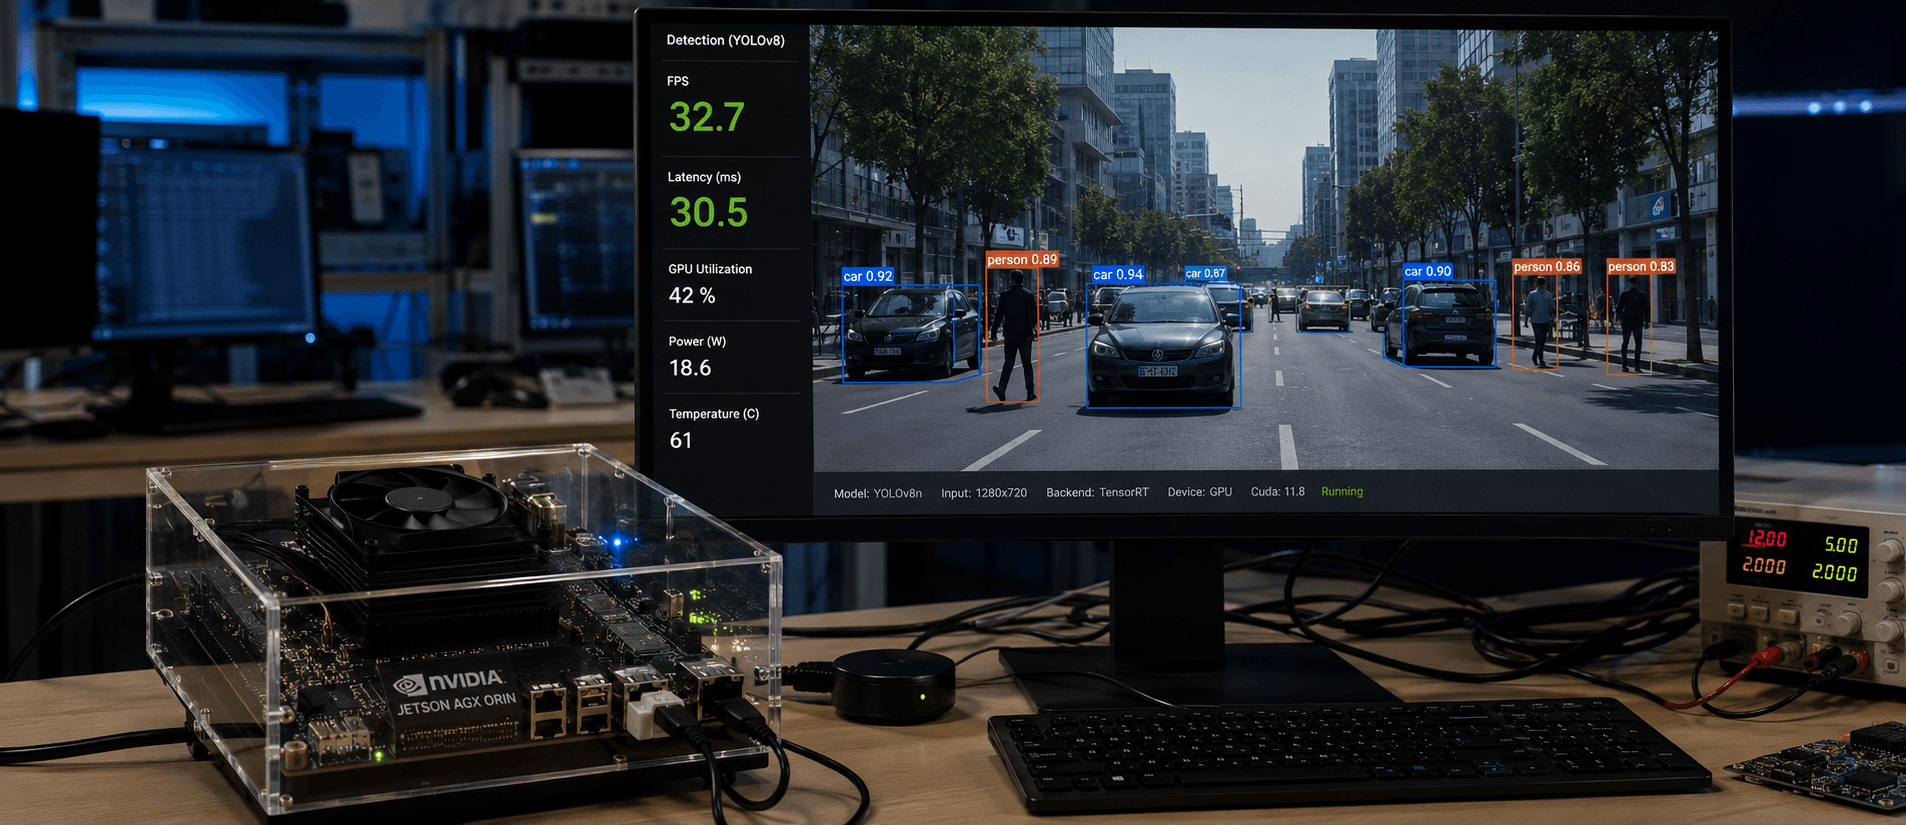
Model optimization matters more than your motion model. Here are the numbers.
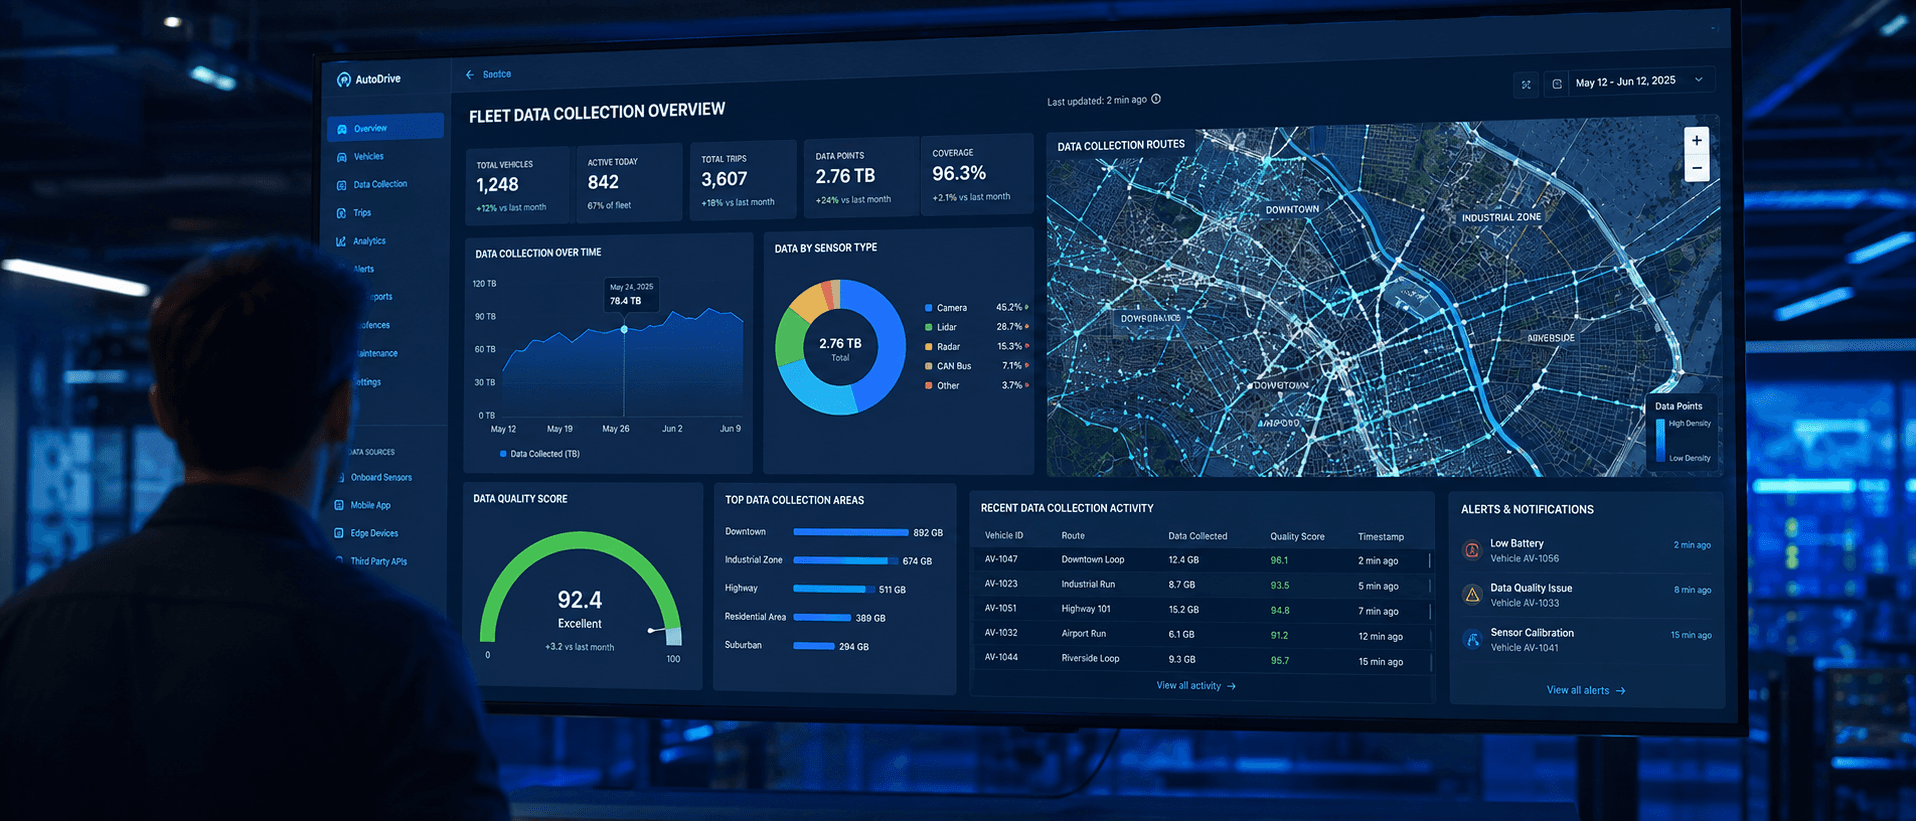
The scale, the method, and the top five failure patterns nobody put in the original training set.