 BlinkThorLabs
Watching PID Actually Work: A Night With EncoderMotor_PID_Demo
"set" said 1.000. "actual" never quite agreed with it. That disagreement is the whole lesson.
Hoang works across the low-level automotive platform and the services that connect it to a wider vehicle system. His experience includes AUTOSAR MCAL, flash-bootloader security, embedded Linux, telematics and simulation gateways. As Senior Embedded Software Engineer for AUTOSAR & Cybersecurity, he brings a detailed view of how software reaches the target, communicates with other components and behaves during testing, updates and recovery.
FPT Software, Automotive SoC and microcontroller programs
His MCAL experience covers requirements, design, implementation, unit tests and integration tests for automotive platforms. Work with ARM and RH850 targets includes C0/C1 coverage, Cantata, CS+ and TRACE32 debugging. Radar-software verification adds GoogleTest, MC/DC test design, requirement mapping and the investigation of build/test environments before ECU execution.
Vehicle-control-unit programs, Cybersecurity controls
Hoang has implemented flash-bootloader rollback protection and diagnostic-triggered mechanisms that help prevent vulnerable software downgrades. The work includes specification updates, verification criteria, CAPL tests and validation using CANoe and TRACE32. This provides practical experience with a security control at the boundary between diagnostic communication, software-version policy and target behavior.
FPT Software, CARLA/ROS 2/VSS and Linux applications
His simulation work includes a Rust gateway converting CARLA data to VSS through ROS 2 and supporting bidirectional control with validation tools. Telematics experience includes emergency-call features, simulation tests and log-based debugging. Embedded Linux projects cover SPI communication, media applications, Qt/QML HMI and a Yocto-based distribution, connecting device interfaces to user-facing software.
His academic background includes a Bachelor of Engineering in Mechatronics Engineering Technology at the Industrial University of Ho Chi Minh City. He holds a Master’s degree in Mechatronics Engineering. Technical tools include C/C++, Python, Rust, CAPL, Qt/QML, CANoe, TRACE32, Cantata, GoogleTest, ROS 2 and Yocto. His professional development also includes Japanese-language training at JLPT N4 level.
Hoang can contribute to an AUTOSAR platform, secure-update workstream or embedded integration program through implementation, target debugging and verification. He is a fit for problems involving MCAL behavior, diagnostics, rollback rules, vehicle-signal gateways or the integration of Linux and microcontroller components. His approach keeps requirements, observable target behavior and test evidence connected.
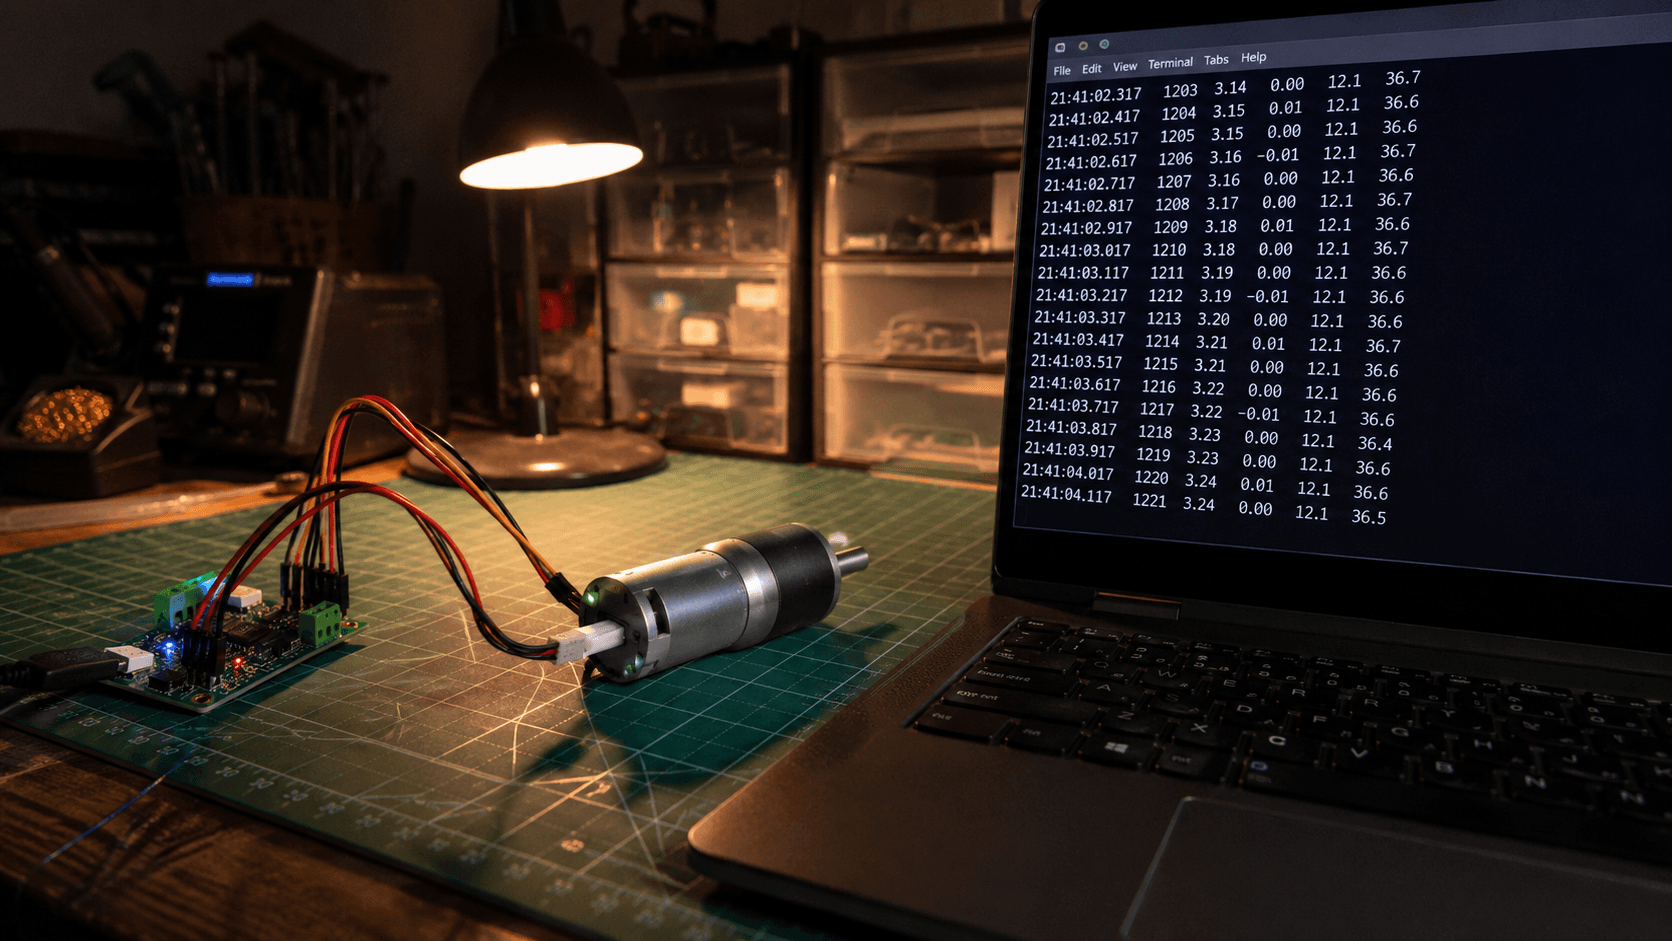
"set" said 1.000. "actual" never quite agreed with it. That disagreement is the whole lesson.
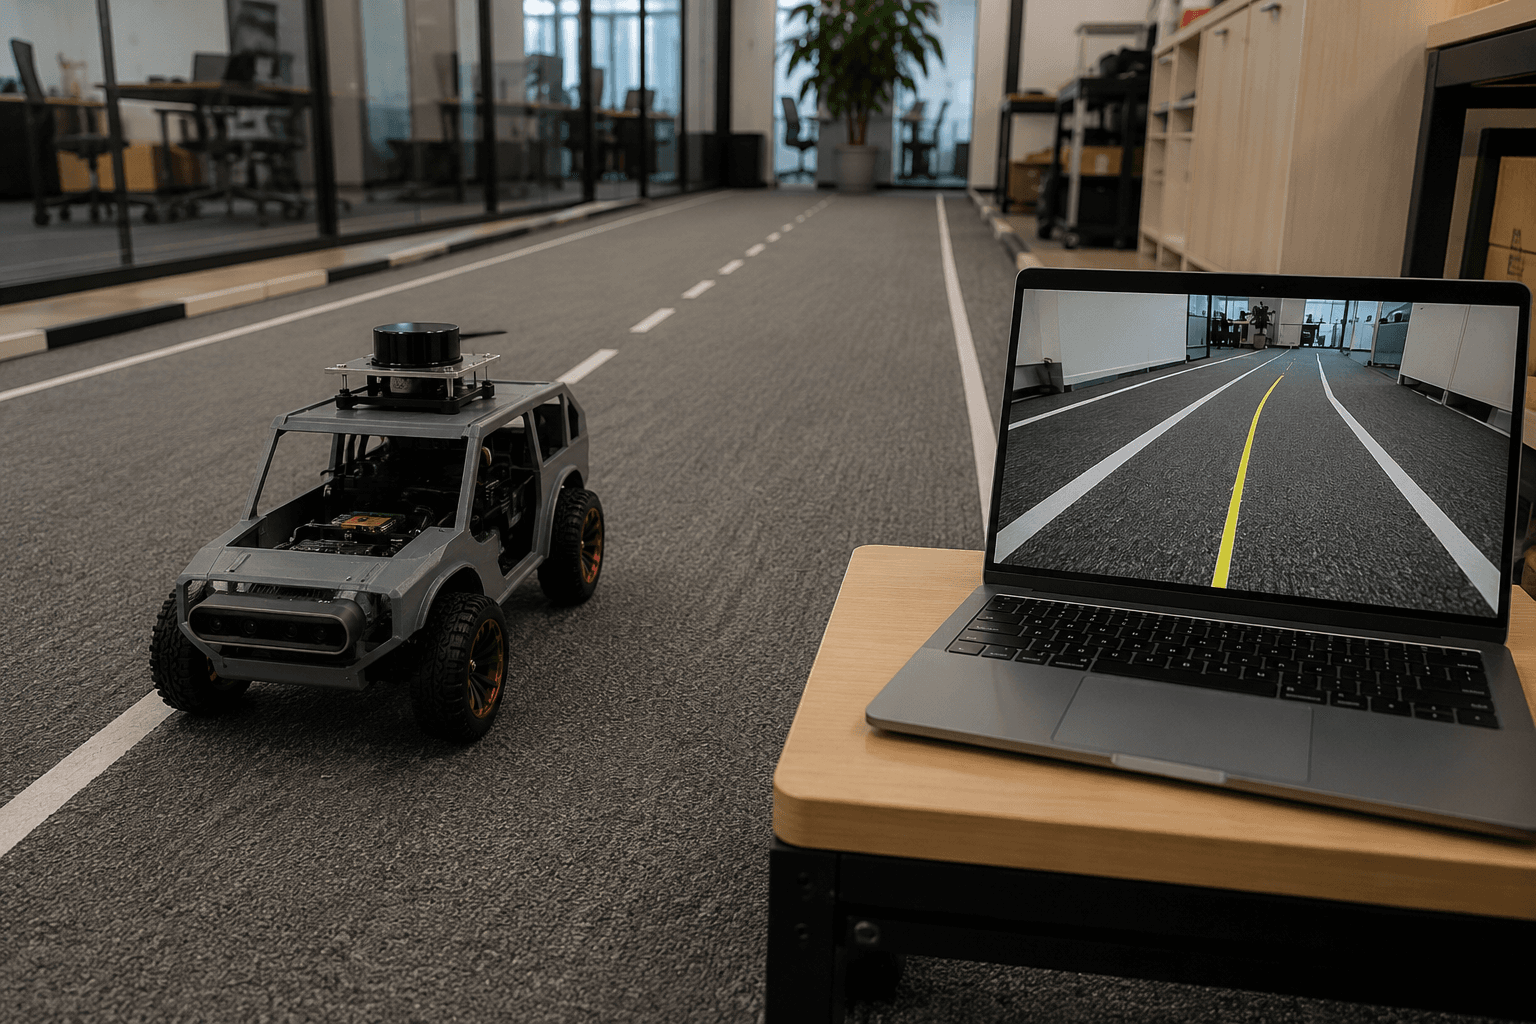
Monday to Friday, one road mat, one stubborn ceiling light, and the moment lane_detect.py finally made sense.
No log. No crash dump. No pattern. Just a system that stops existing, and a much longer list of suspects than the one that turned out to be guilty.
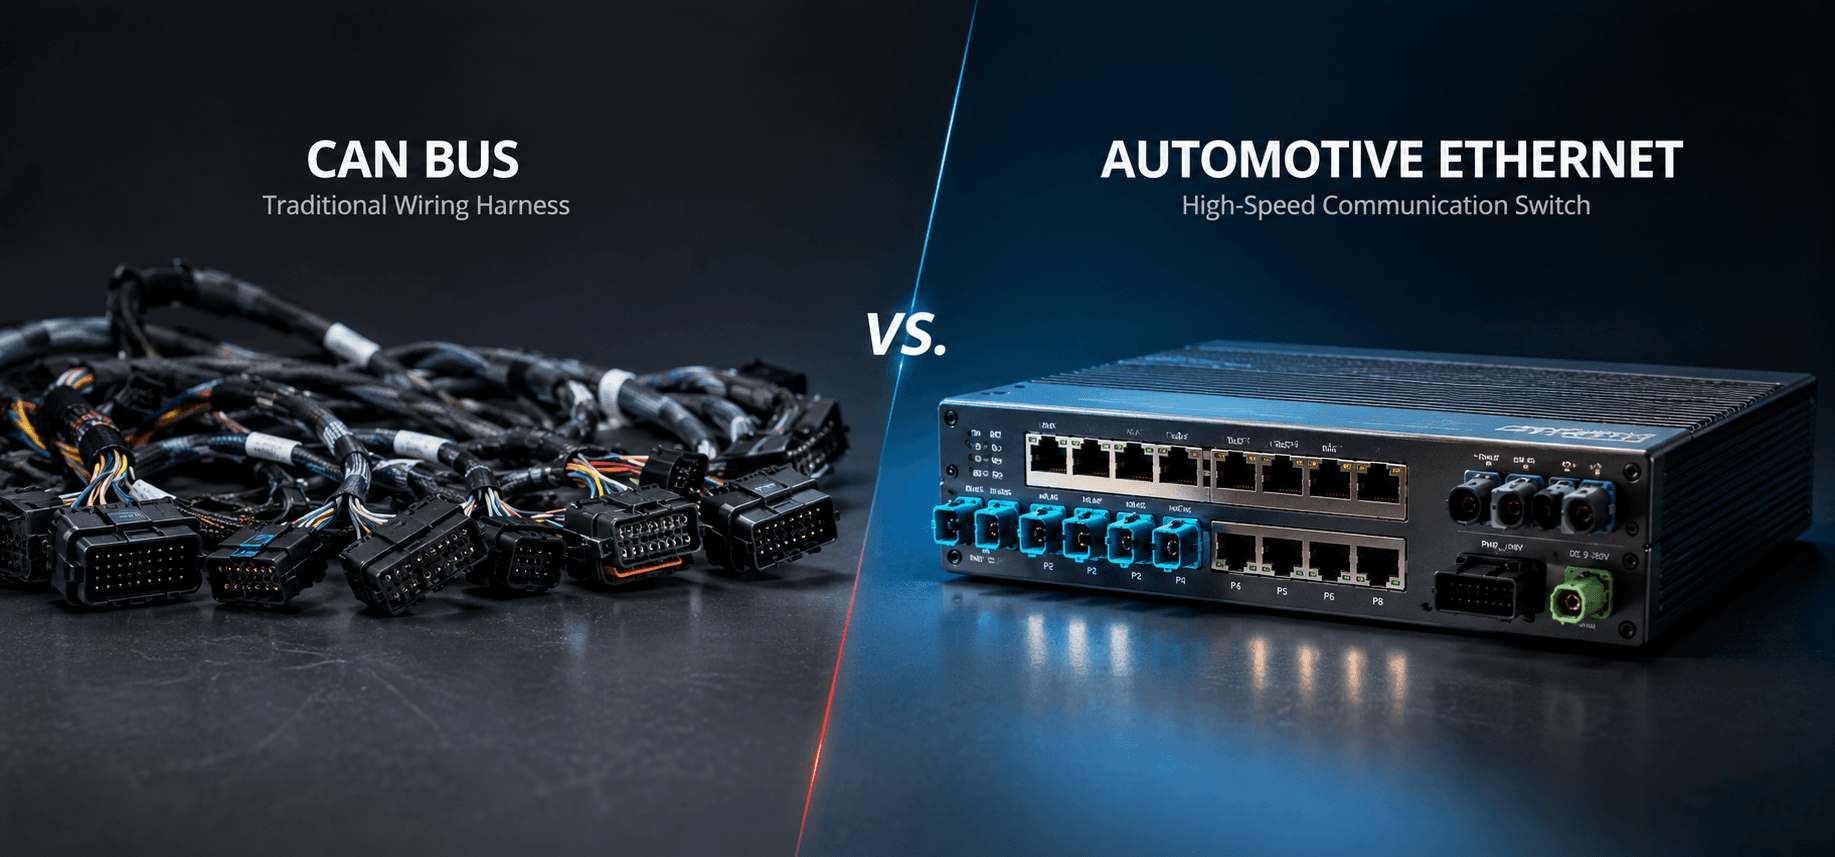
Physical vs functional addressing, and the multi-client problem CAN never made you think about.
A practical structure for FMEAs and safety cases that actually survives an assessor.